
测绘学报 ›› 2026, Vol. 55 ›› Issue (10): 1756-1767.doi: 10.11947/j.AGCS.2026.20250469
冯进凯( ), 李姗姗, 冯绪(), 李新星, 范昊鹏, 范雕, 万宏发
收稿日期:2025-11-11
修回日期:2026-10-08
出版日期:2026-11-16
发布日期:2026-11-16
通讯作者:
冯绪
E-mail:fengjinkai1992@163.com;geodesy-fx@163.com
作者简介:冯进凯(1992—),男,博士,讲师,研究方向为物理大地测量。E-mail:fengjinkai1992@163.com
基金资助:
Jinkai Feng(), Shanshan Li, Xu Feng(), Xinxing Li, Haopeng Fan, Diao Fan, Hongfa Wan
Received:2025-11-11
Revised:2026-10-08
Online:2026-11-16
Published:2026-11-16
Contact:
Xu Feng
E-mail:fengjinkai1992@163.com;geodesy-fx@163.com
About author:Feng Jinkai (1992—), male, PhD, lecturer, majors in physical geodesy. E-mail: fengjinkai1992@163.com
Supported by:摘要:
飞机地磁辅助惯性导航时,机舱内磁敏传感器容易受到电子设备(on-board electronic equipment,OBE)电流/压的磁干扰,导致地磁场实时测量精度降低,进而影响匹配导航结果。对此,本文提出了一种顾及OBE电流/压特征的在线补偿增益扩展卡尔曼滤波(extend Kalman filter,EKF)算法。该方法在Tolles-Lawson(TL)模型的基础上,通过残差相关性逐次引入特征值的方式实现了TL模型离线补偿的优化,并将其作为新增状态量引入EKF中,EKF状态量由15维拓展至56维,补偿参数在滤波过程中实时更新,实现了舱内磁干扰的在线补偿,为地磁匹配导航中舱内磁补偿带来了一种思路。实测数据结果显示,优化后的TL模型离线补偿精度提升显著,两条航线的补偿精度分别达到5.04 nT和6.41 nT;在线补偿模式下,新增状态量具有较强的可观性,补偿误差由12.07 nT和19.56 nT分别降至4.68 nT和3.98 nT;导航精度由48.394 6 m和41.752 3 m分别提升至33.015 6 m和13.324 8 m。
中图分类号:
冯进凯, 李姗姗, 冯绪, 李新星, 范昊鹏, 范雕, 万宏发. 顾及OBE电特征的舱内在线补偿增益EKF算法[J]. 测绘学报, 2026, 55(10): 1756-1767.
Jinkai Feng, Shanshan Li, Xu Feng, Xinxing Li, Haopeng Fan, Diao Fan, Hongfa Wan. An augmented EKF with in-cabin online magnetic compensation considering OBE electric characteristics[J]. Acta Geodaetica et Cartographica Sinica, 2026, 55(10): 1756-1767.
图1
两条航线分布"
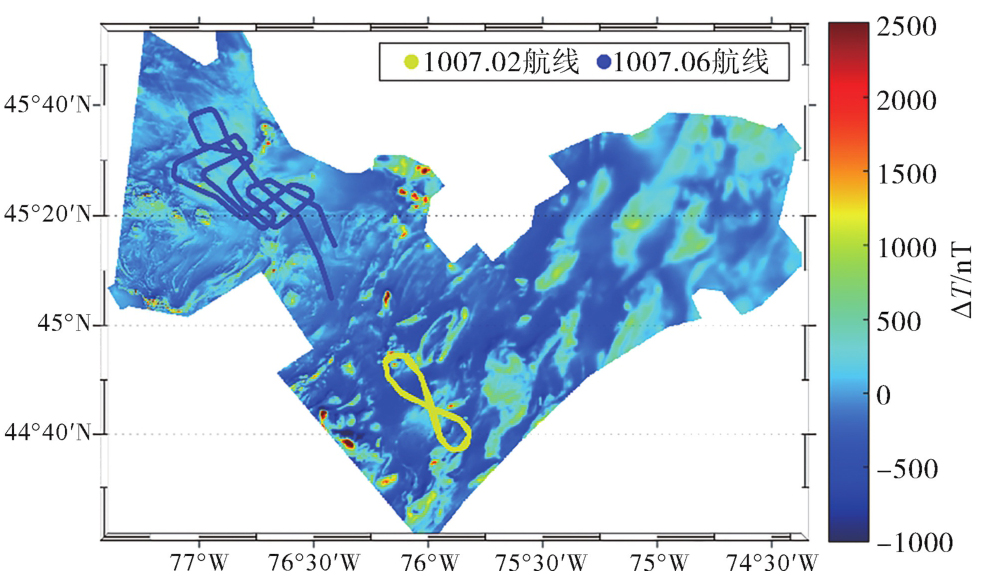
图2
磁力计位置及载体坐标系"
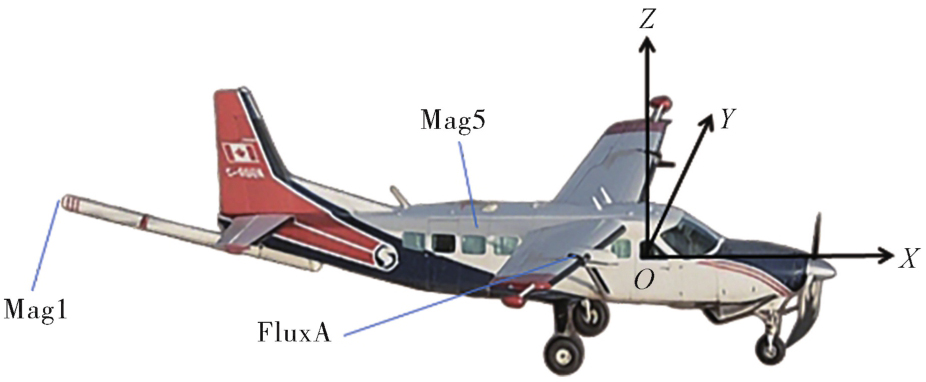
表1
数据集采集数据标识符及其描述"
| 电流相关 | 电压相关 | ||
|---|---|---|---|
| 标识符 | 来源 | 标识符 | 来源 |
| cur_com_1 | 飞机COM1无线电 | vol_acpwr | 飞机电源电压 |
| cur_ac_hi | 空调风扇高速档 | vol_outpwr | 系统输出电源电压 |
| cur_ac_lo | 空调风扇低速档 | vol_bat_1 | 电池1电压 |
| cur_tank | 客舱燃油泵 | vol_bat_2 | 电池2电压 |
| cur_flap | 飞机襟翼马达 | vol_res_p | 旋变器板/解算器板正极 |
| cur_strb | 闪光灯/频闪灯 | vol_res_n | 旋变器板/解算器板负极 |
| cur_srvo_o | INS外部伺服 | vol_back_p | 母板/主板正极 |
| cur_srvo_m | INS中间伺服 | vol_back_n | 母板/主板负极 |
| cur_srvo_i | INS内部伺服 | vol_gyro_1 | 陀螺仪1电压 |
| cur_heat | INS加热器 | vol_gyro_2 | 陀螺仪2电压 |
| cur_acpwr | 飞机电源(交流电) | vol_acc_p | INS加速度计正极 |
| cur_outpwr | 系统输出电源 | vol_acc_n | INS加速度计负极 |
| cur_bat_1 | 电池1 | vol_block | 模块电压 |
| cur_bat_2 | 电池2 | vol_back | 背板电压 |
| vol_srvo | 伺服系统电压 | ||
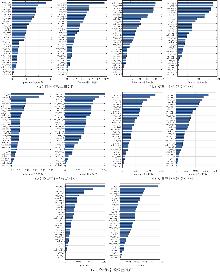
图3
各特征与各个模型残余相关性"
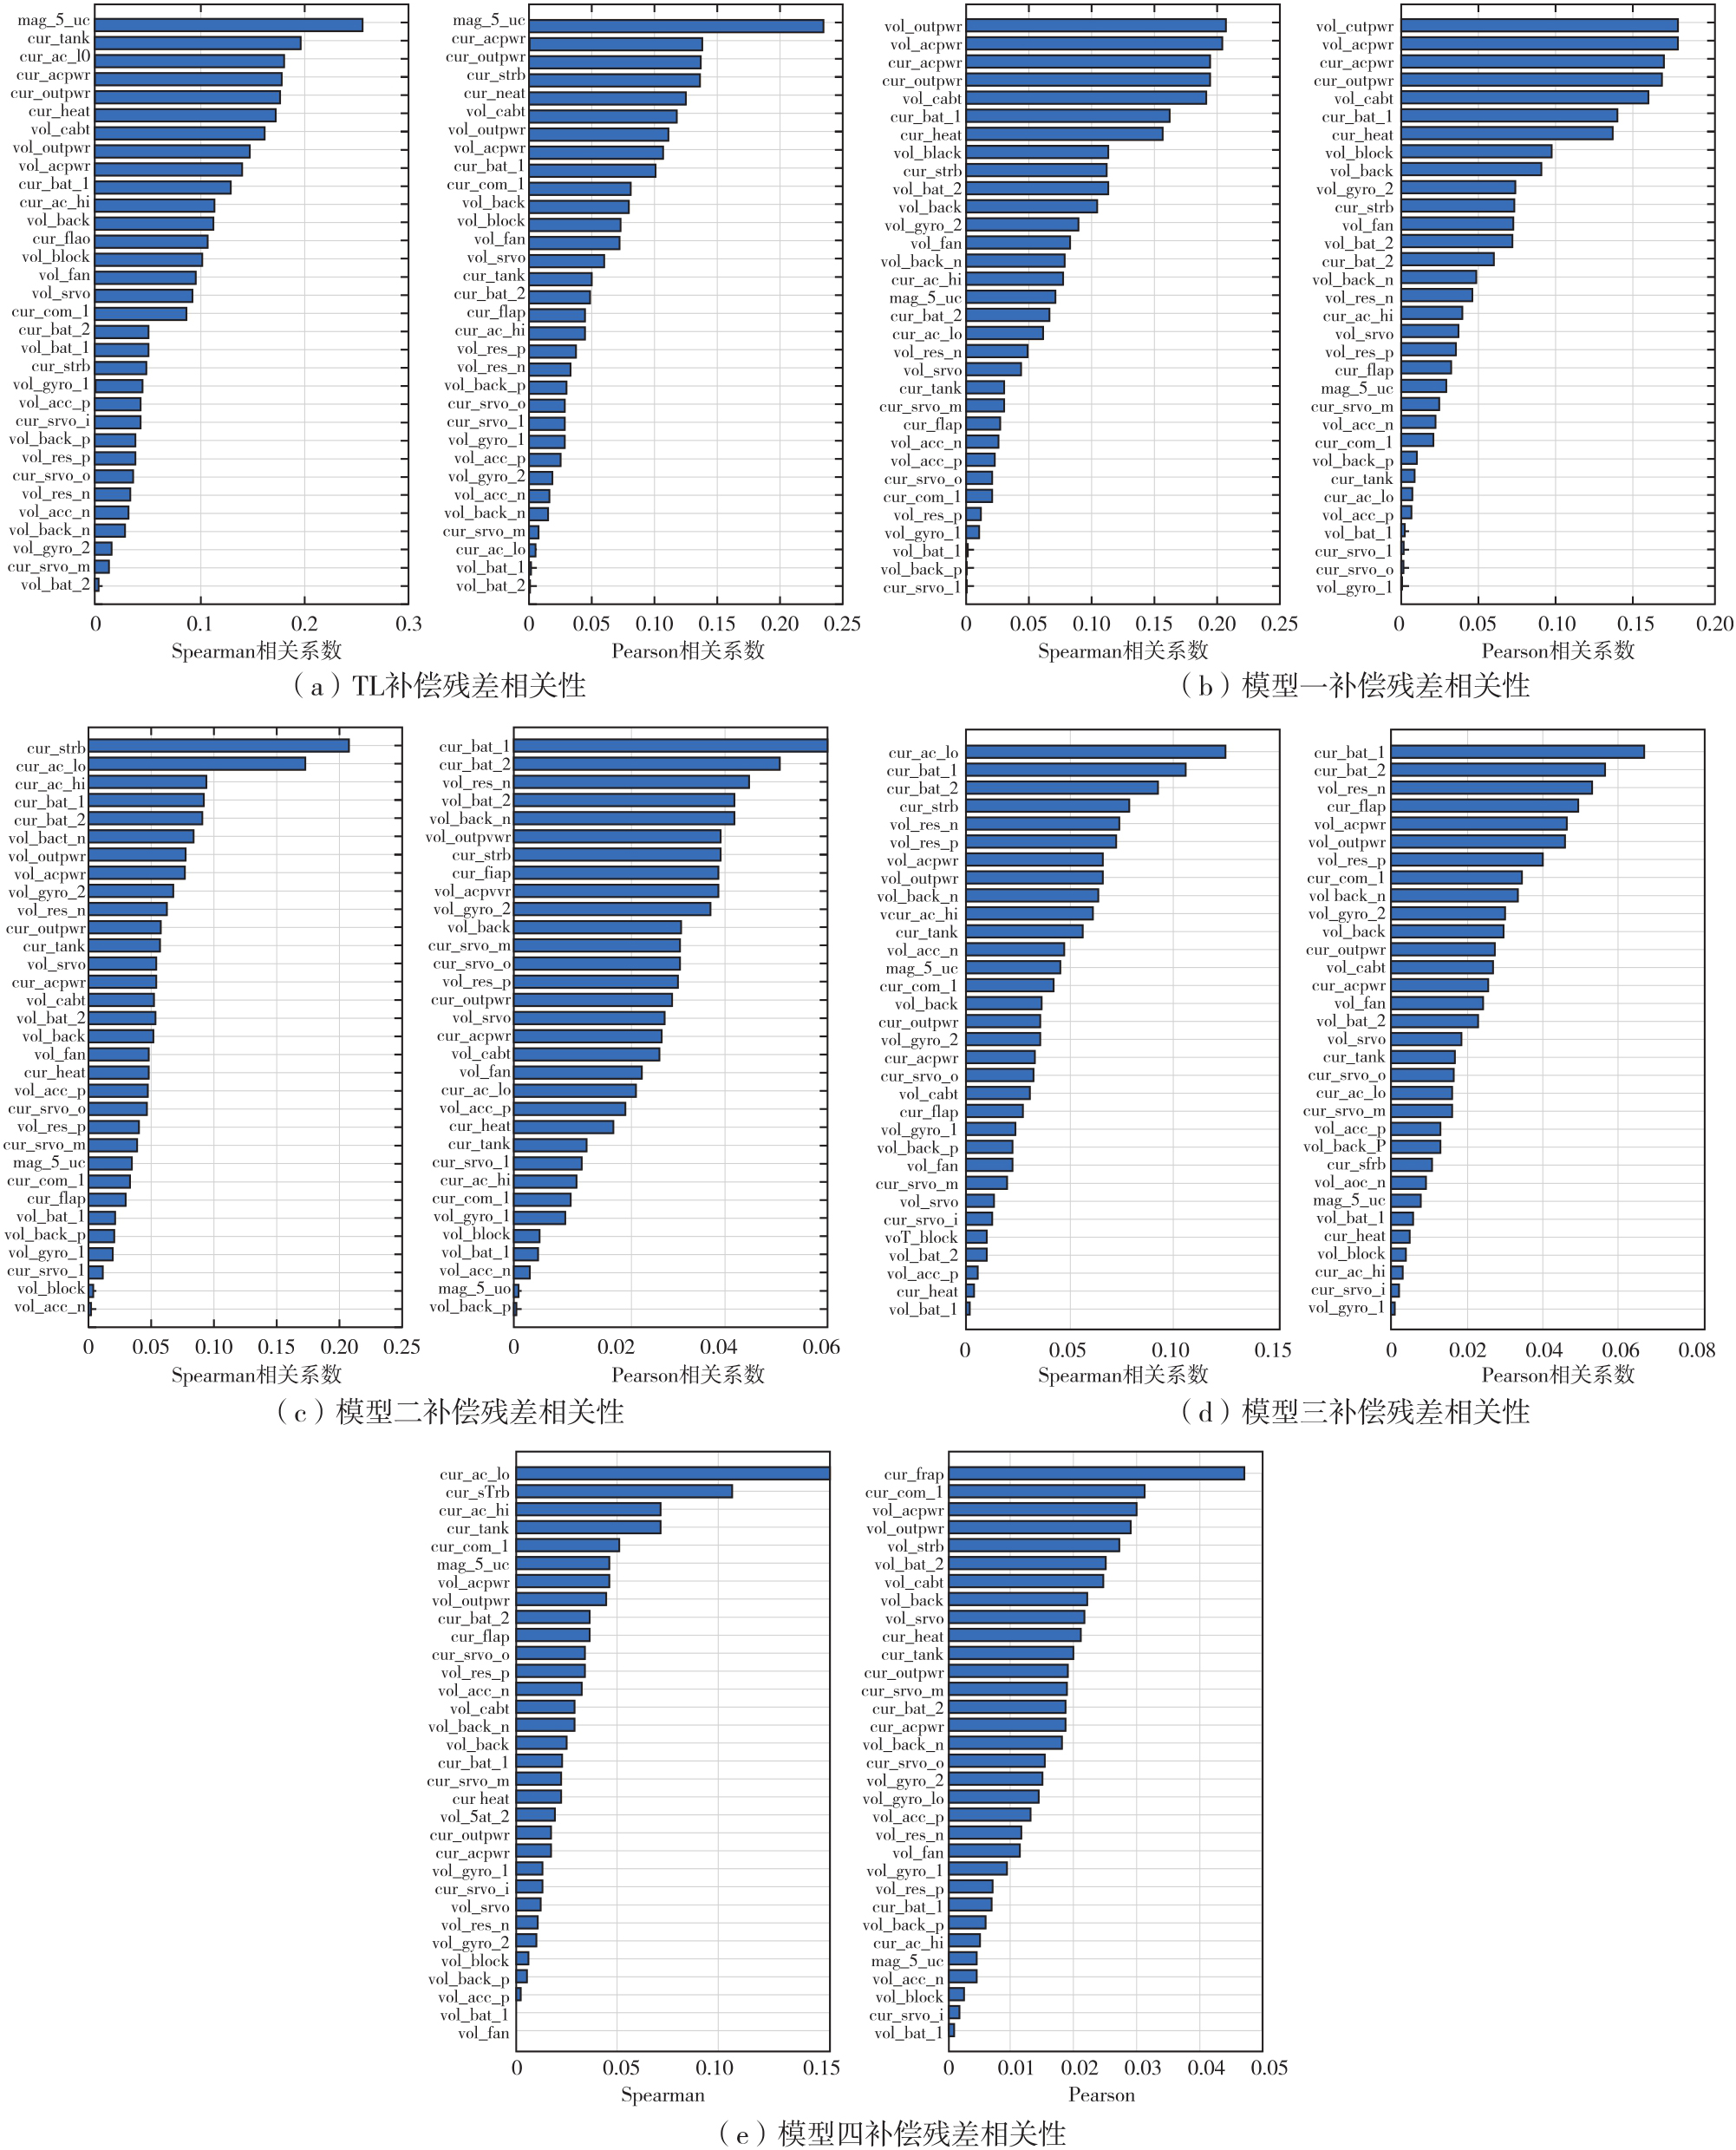
表2
两条航线离线模型的补偿精度统计"
| 模型 | 1007.02航线/nT | 改进率/(%) | 1007.06航线/nT | 改进率/(%) |
|---|---|---|---|---|
| TL模型 | 11.12 | 9.158 3 | 19.87 | 5.337 3 |
| 模型一 | 6.91 | 14.738 1 | 9.09 | 11.666 9 |
| 模型二 | 4.93 | 20.657 3 | 7.58 | 13.991 1 |
| 模型三 | 5.56 | 18.316 6 | 7.08 | 14.979 1 |
| 模型四 | 5.05 | 20.166 4 | 6.41 | 16.544 8 |
| 模型五 | 5.05 | 20.166 4 | 6.41 | 16.544 8 |
图4
两条航线各模型的补偿效果"
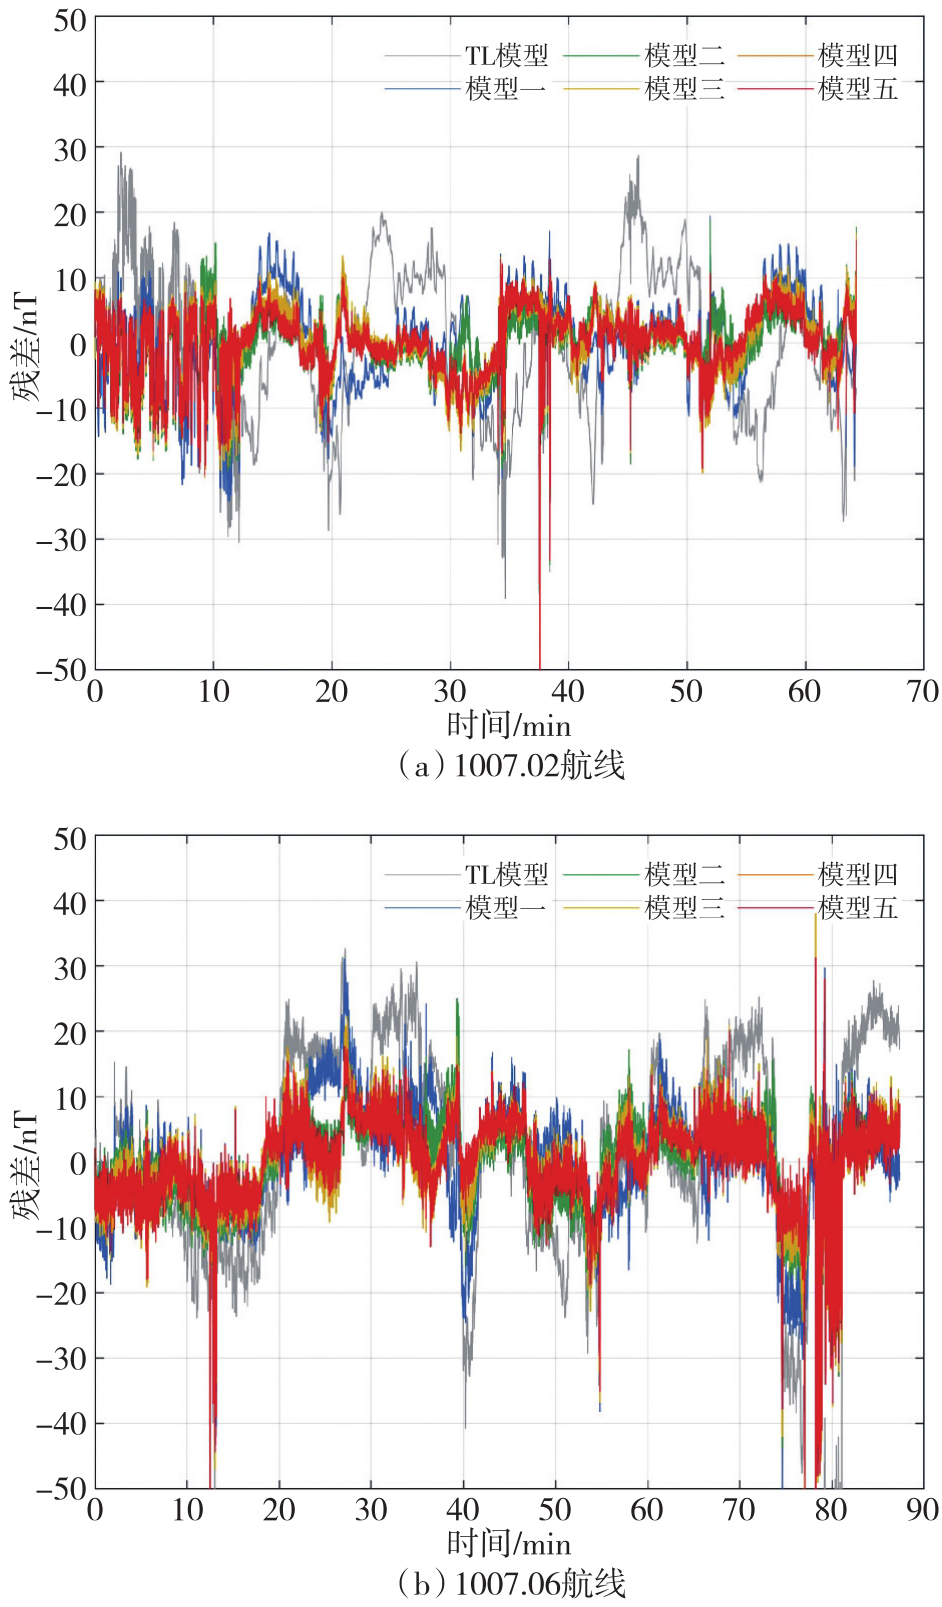
表3
陀螺仪和加速度参数"
| 惯导误差项 | 常值零偏 | 随机游走 |
|---|---|---|
| 陀螺仪 | 0.0015(°)/h | 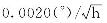 |
| 加速度计 | 24.5 mGal | 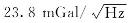 |
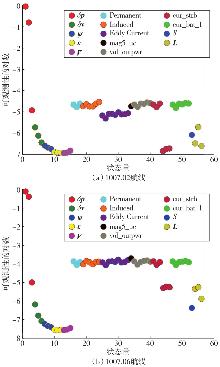
图5
两条航线中各时刻状态量可观测度中值"
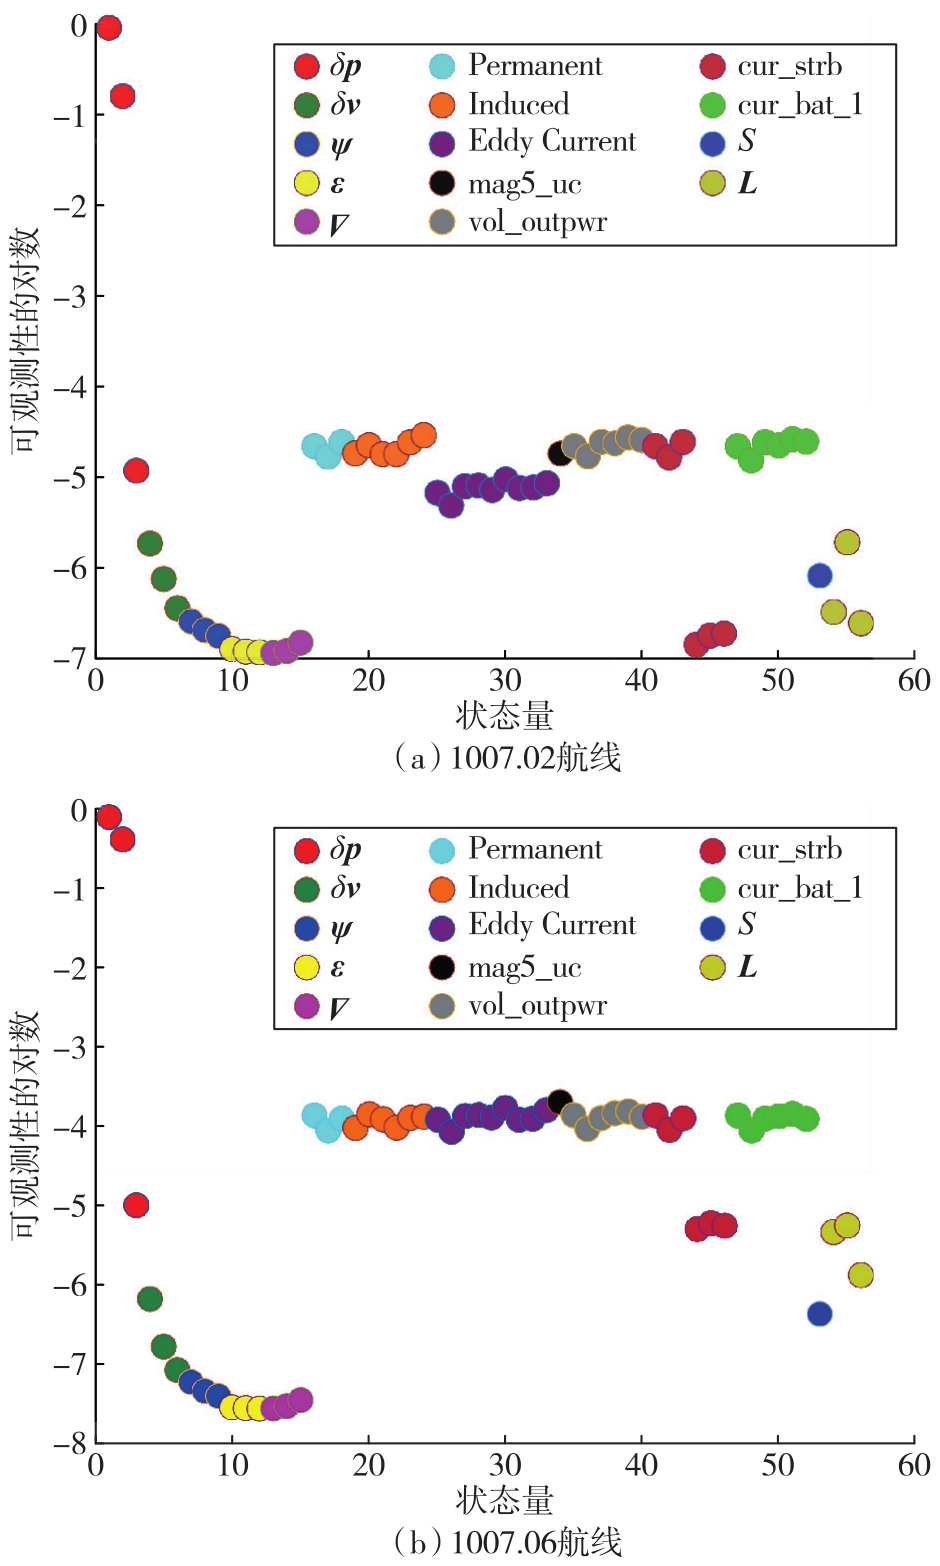
图6
补偿模型各部分协方差的变化"

图7
两条航线在线补偿结果"
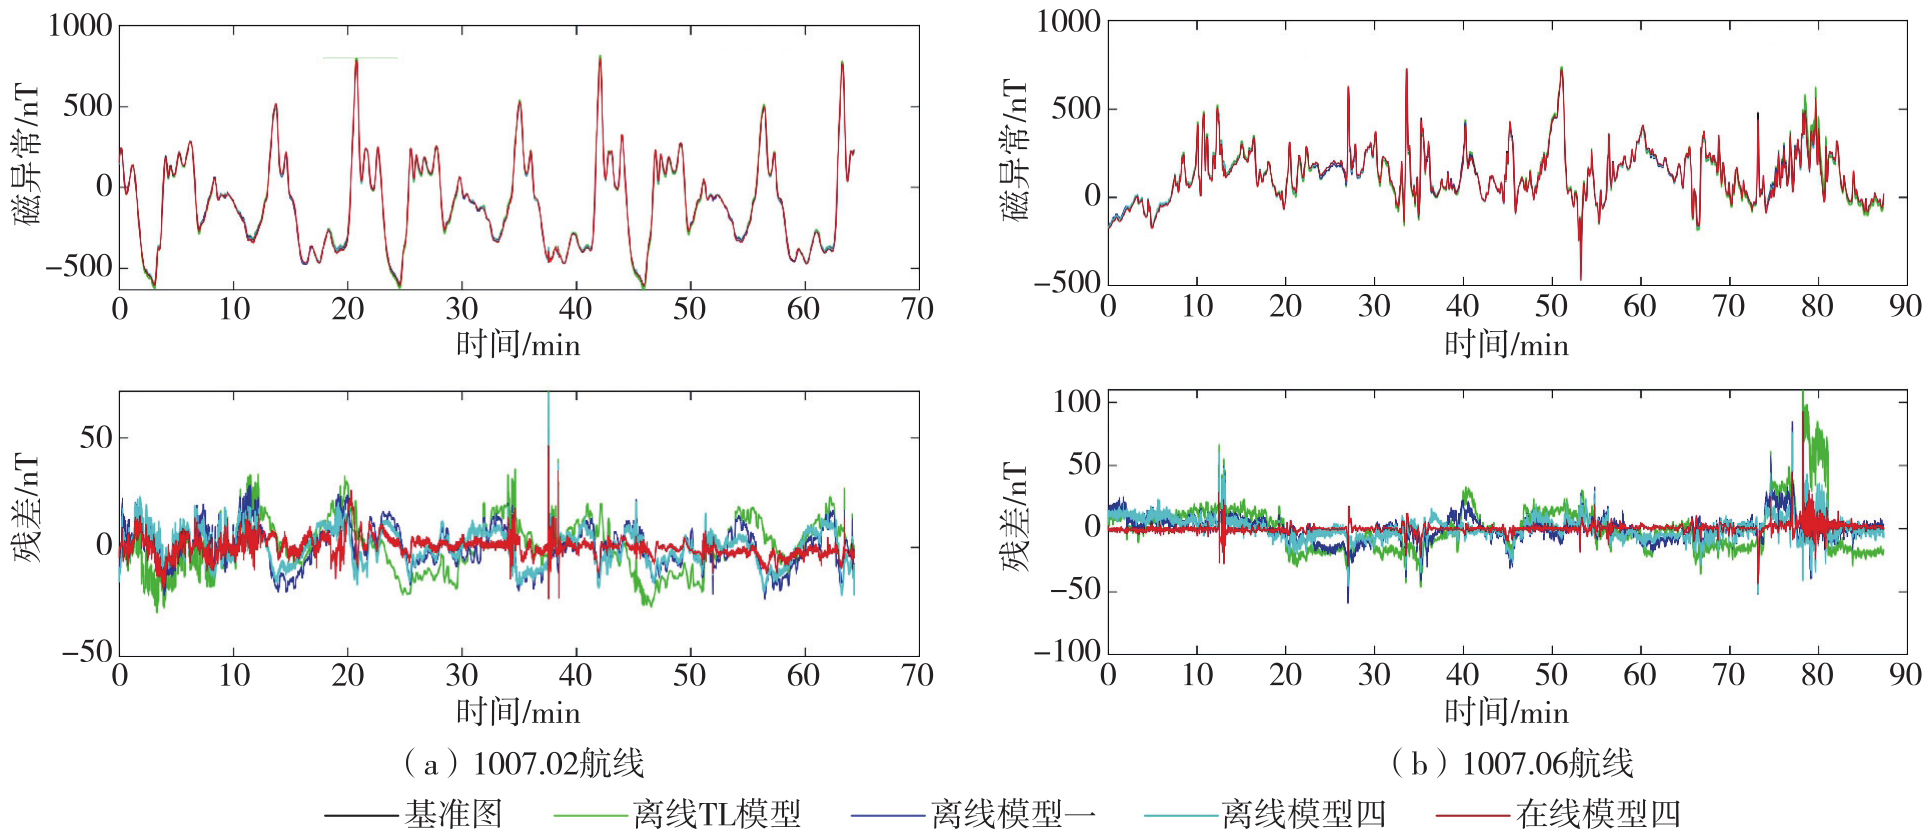
表4
两条航线补偿结果"
| 模型 | 1007.02航线/nT | 改进率/(%) | 1007.06航线/nT | 改进率/(%) |
|---|---|---|---|---|
| 离线TL模型 | 12.07 | 8.437 5 | 19.56 | 5.421 9 |
| 离线模型一 | 9.59 | 10.619 4 | 10.68 | 9.930 0 |
| 离线模型四 | 8.01 | 12.714 1 | 8.49 | 12.491 4 |
| 在线模型四 | 4.68 | 21.760 8 | 3.98 | 26.646 3 |
图8
两条航线的北向东向位置误差"
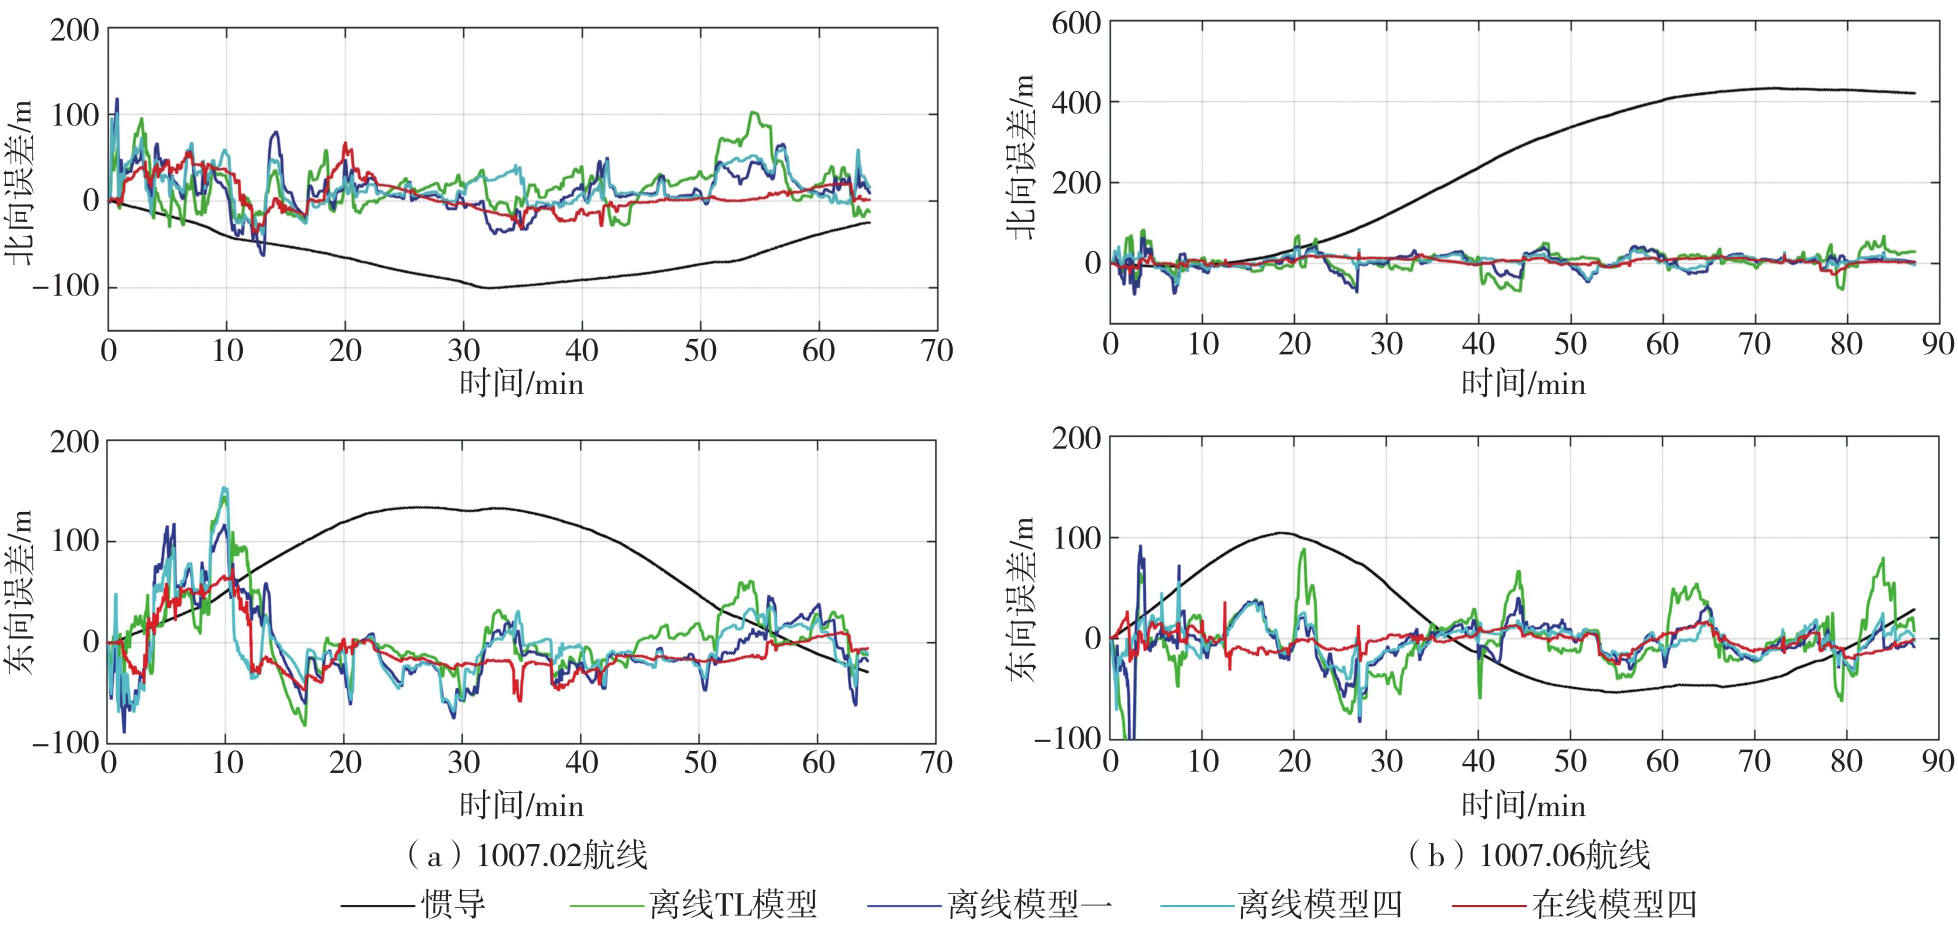
表5
不同补偿模型下的位置误差统计"
| 航线 | 位置误差/m | ||||
|---|---|---|---|---|---|
| 惯导 | 离线TL模型 | 离线模型一 | 离线模型四 | 在线模型四 | |
| 1007.02 | 111.861 0 | 48.394 6 | 47.011 7 | 44.144 2 | 33.015 6 |
| 1007.06 | 299.573 7 | 41.752 3 | 30.356 3 | 20.757 1 | 13.324 8 |
| [1] |
杨元喜, 任夏, 张强, 等. 量子PNT发展及其关键技术[J]. 测绘学报, 2026, 55(1): 1-9. DOI: .
doi: 10.11947/j.AGCS.2026.20251218 |
|
Yang Yuanxi, Ren Xia, Zhang Qiang, et al. The development and key technologies of quantum PNT[J]. Acta Geodaetica et Cartographica Sinica, 2026, 55(1): 1-9. DOI: .
doi: 10.11947/j.AGCS.2026.20251218 |
|
| [2] | Westbrook T. The global positioning system and military jamming: the geographies of electronic warfare[J]. Journal of Strategic Security, 2019, 12(2): 1-16. |
| [3] | Canciani A J, Raquet J. Absolute positioning using the Earth's magnetic anomaly field: magnetic anomaly navigation[J]. Navigation, 2016, 63(2): 111-126. |
| [4] | Canciani A J, Raquet J. Airborne magnetic anomaly navigation[J]. IEEE Transactions on Aerospace and Electronic Systems, 2017, 53(1): 67-80. |
| [5] | Canciani A J. Magnetic navigation on an F-16 aircraft using online calibration[J]. IEEE Transactions on Aerospace and Electronic Systems, 2022, 58(1): 420-434. |
| [6] | Bonifaz J D. Magnetic navigation using online calibration filter analysis[D]. Ohio: Air Force Institute of Technology, 2022. |
| [7] | Liu Yuxin, Li Wen, Wei Dongyan, et al. A modified aeromagnetic compensation method robust to in-cabin OBE interferences[J]. Navigation Positioning and Timing, 2024, 11(4): 38-46. |
| [8] | 冯进凯, 李姗姗, 冯绪, 等. 一种顾及多OBE特征的飞机舱内磁补偿算法[J]. 中国惯性技术学报, 2026, 34(3): 264-274. |
| Feng Jinkai, Li Shanshan, Feng Xu, et al. A magnetic compensation algorithm for aircraft cabins with consideration of multiple OBE characteristics[J]. Journal of Chinese Inertial Technology, 2026, 34(3): 264-274. | |
| [9] | 冯绪, 柴洪洲, 冯进凯, 等. 基于GBRT算法的舱内航磁干扰补偿[J/OL]. 北京航空航天大学学报, [2025-11-11]. https://doi.org/10.13700/j.bh.1001-5965.2025.0640. |
| Feng Xu, Chai Hongzhou, Feng Jinkai, et al. Aeromagnetic compensation in cabin magnetometers based on GBRT algorithm[J/OL]. Journal of Beijing University of Aeronautics and Astronautics, [2025-11-11]. https://doi.org/10.13700/j.bh.1001-5965.2025.0640. | |
| [10] | Wang Yizhen, Han Qi, Zhan Dechen, et al. A data-driven OBE magnetic interference compensation method[J]. Sensors, 2022, 22(20): 7732. |
| [11] | Gnadt A R. Machine learning-enhanced magnetic calibration for airborne magnetic anomaly navigation[EB/OL]. [2025-09-07]. https://arc.aiaa.org/doi/10.251416.2022-1760. |
| [12] | Gnadt A R. Advanced aeromagnetic compensation models for airborne magnetic anomaly navigation[D]. Cambridge: Massachusetts Institute of Technology, 2022. |
| [13] |
Liu Li, Xu Qingfeng, Gu Hui, et al. Aeromagnetic compensation algorithm based on Levenberg-Marquard neural network[J]. Journal of Geodesy and Geoinformation Science, 2021, 4(4): 74-83. DOI: .
doi: 10.11947/j.JGGS.2021.0406 |
| [14] | Ge Lin, Han Qi, Qiao Zhi, et al. Innovative aeromagnetic compensation techniques for in-cabin magnetometers amidst complex OBE interference[J]. IEEE Sensors Journal, 2024, 24(20): 32801-32812. |
| [15] | 严恭敏, 翁浚. 捷联惯导算法与组合导航原理[M]. 西安: 西北工业大学出版社, 2019. |
| Yan Gongmin, Weng Jun. Strapdown inertial navigation algorithm and integrated navigation principle[M]. Xi'an: Northwestern Polytechnical University Press, 2019. | |
| [16] | Alken P, Thébault E, Beggan C D, et al. International geomagnetic reference field: the thirteenth generation[J]. Earth, Planets and Space, 2021, 73(1): 49. |
| [17] | 万宏发, 李姗姗, 李新星, 等. 重力辅助惯性导航可观测度分析[J]. 北京航空航天大学学报, 2026, 52(7): 2496-2508. |
| Wan Hongfa, Li Shanshan, Li Xinxing, et al. Analysis of observable degree of gravity aided inertial navigation[J]. Journal of Beijing University of Aeronautics and Astronautics, 2026, 52(7): 2496-2508. | |
| [18] | Wang Qi, Wang Lixin, Qin Weiwei, et al. A local observability analysis method for a time-varying nonlinear system and its application in the continuous self-calibration system[J]. Science China Information Sciences, 2020, 64(1): 11920. |
| [19] | 杨晓霞, 阴玉梅. 可观测度的探讨及其在捷联惯导系统可观测性分析中的应用[J]. 中国惯性技术学报, 2012, 20(4): 405-409. |
| Yang Xiaoxia, Yin Yumei. Discussions on observability and its applications in SINS[J]. Journal of Chinese Inertial Technology, 2012, 20(4): 405-409. | |
| [20] | Bernard P. Observer design for nonlinear systems[M]. Cham: Springer International Publishing, 2019. |
| [21] | Lu Jiazhen, Xie Lili, Zhang Chunxi, et al. A simplified method of PWCS observability analysis theory by research of general expressions[C]//Proceedings of 2013 International Conference on Mechatronic Sciences, Electric Engineering and Computer. Shengyang: IEEE, 2013: 154-162. |
| [22] | Gnadt A R, Belarge J, Canciani A, et al. Signal enhancement for magnetic navigation challenge problem[EB/OL]. [2025-10-11]. https://doi.org/10.48550/arXiv.2007.12158. |
| [23] | Cui Xufei, Li Yibing, Wang Qiuying. Enhanced vehicle heading estimation for magnetometer/gyroscope integration with random magnetic interference detection based on Pearson correlation coefficient[J]. IEEE Transactions on Instrumentation and Measurement, 2024, 73: 9504116. |
| [24] | 李姗姗. 水下重力辅助惯性导航的理论与方法研究[D]. 郑州: 信息工程大学, 2010. |
| Li Shanshan. Research on the theory and method of underwater gravity-aided inertial navigation[D]. Zhengzhou: Information Engineering University, 2010. | |
| [25] | 毛宁, 李安, 许江宁, 等. 惯性/重力组合导航可观测性分析及鲁棒滤波方法[J]. 武汉大学学报(信息科学版), 2024, 49(11): 2113-2121. |
| Mao Ning, Li An, Xu Jiangning, et al. Observability analysis and robust fusion algorithms of INS/gravity integrated navigation[J]. Geomatics and Information Science of Wuhan University, 2024, 49(11): 2113-2121. |
| [1] | 李兆权, 纪兵, 张涛, 周东权, 边少锋. 顾及物理特征的局部参考椭球参数计算[J]. 测绘学报, 2026, 55(9): 1521-1529. |
| [2] | 禤键豪, 陈秋杰, 张兴福, 沈云中. SWOT测高数据反演高分辨率海洋重力场增益分析[J]. 测绘学报, 2026, 55(7): 1158-1170. |
| [3] | 钱妮佳, 张迅, 常国宾, 卞和方, 杨化超, 韩先楠. 最小二乘配置的贪婪稀疏近似算法[J]. 测绘学报, 2026, 55(5): 850-865. |
| [4] | 邢志斌, 李姗姗, 田苗, 孟瑶, 杨娜, 李倩, 常品要. 10 800阶地形球谐系数模型构建的FFT块对角最小二乘法[J]. 测绘学报, 2026, 55(1): 36-45. |
| [5] | 武矿超. GNSS时频信号传递测定重力位及正高方法研究[J]. 测绘学报, 2025, 54(11): 2106-2106. |
| [6] | 谭勖立, 李姗姗, 黄志勇, 潘宗鹏, 范雕, 万宏发, 裴宪勇, 徐振邦. ChiGaM卫星静态重力场模型构建与分析[J]. 测绘学报, 2025, 54(10): 1798-1811. |
| [7] | 于红娟. 基于SLR数据的地心运动及地球扁率变化研究[J]. 测绘学报, 2025, 54(10): 1907-1907. |
| [8] | 于道成. 多源卫星测高数据反演南海最佳重力场[J]. 测绘学报, 2025, 54(10): 1908-1908. |
| [9] | 李建成, 吴云龙, 姚宜斌, 罗志才. 面向“数据-场景-模式”驱动的卫星重力技术研究进展、挑战与趋势[J]. 测绘学报, 2025, 54(9): 1537-1560. |
| [10] | 章传银, 蒋涛, 柯宝贵. 统一于地固参考系的高程基准重力场理论基础与经典概念更新[J]. 测绘学报, 2025, 54(9): 1561-1571. |
| [11] | 李桢, 贺正航, 施闯. 一种无奇异点的高阶次引力位及其梯度计算方法[J]. 测绘学报, 2025, 54(9): 1572-1582. |
| [12] | 押少帅, 刘新, 周瑞宸, 李真, 边少锋, 郭金运. 基于科学阶段SWOT/KaRIn测高数据反演高精度的垂直重力异常梯度模型[J]. 测绘学报, 2025, 54(9): 1583-1595. |
| [13] | 王翰, 肖云, 关怀魁, 孙玮萱. 熵-PSO双驱优化的改进巴特沃斯重力向下延拓方法[J]. 测绘学报, 2025, 54(9): 1620-1632. |
| [14] | 胡少彬, 陈秋杰, 沈云中, 张兴福. 基于Adams和KSG的短弧积分方程快速离散化方法[J]. 测绘学报, 2025, 54(8): 1416-1426. |
| [15] | 章传银, 王伟, 蒋涛. 地球质心、形状极与多种自转动力学参数联动的监测方法[J]. 测绘学报, 2025, 54(7): 1157-1169. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
