Acta Geodaetica et Cartographica Sinica ›› 2026, Vol. 55 ›› Issue (9): 1630-1640.doi: 10.11947/j.AGCS.2026.20260177
• Photogrammetry and Remote Sensing • Previous Articles Next Articles
Sihan Liu1( ), Shiwei Shao2,3, Yuefeng Lu1,4(), Ziqi Ding1, Chunlin Mu5, Xiaolei Dou5, Chengzhe Lü1, Zhirui Jia1, Zhenjie Jiao1
Received:2026-05-11
Revised:2026-08-28
Online:2026-10-28
Published:2026-10-28
Contact:
Yuefeng Lu
E-mail:25407010889@stumail.sdut.edu.cn;yflu@sdut.edu.cn
About author:Liu Sihan (2004—), female, postgraduate, majors in 3D data processing and modeling. E-mail: 25407010889@stumail.sdut.edu.cn
Supported by:CLC Number:
Sihan Liu, Shiwei Shao, Yuefeng Lu, Ziqi Ding, Chunlin Mu, Xiaolei Dou, Chengzhe Lü, Zhirui Jia, Zhenjie Jiao. Heterogeneous building point cloud registration via deformable self-attention and density-invariant keypoint detection[J]. Acta Geodaetica et Cartographica Sinica, 2026, 55(9): 1630-1640.
Fig. 1
Overall architecture of the cross-source point cloud registration network model"
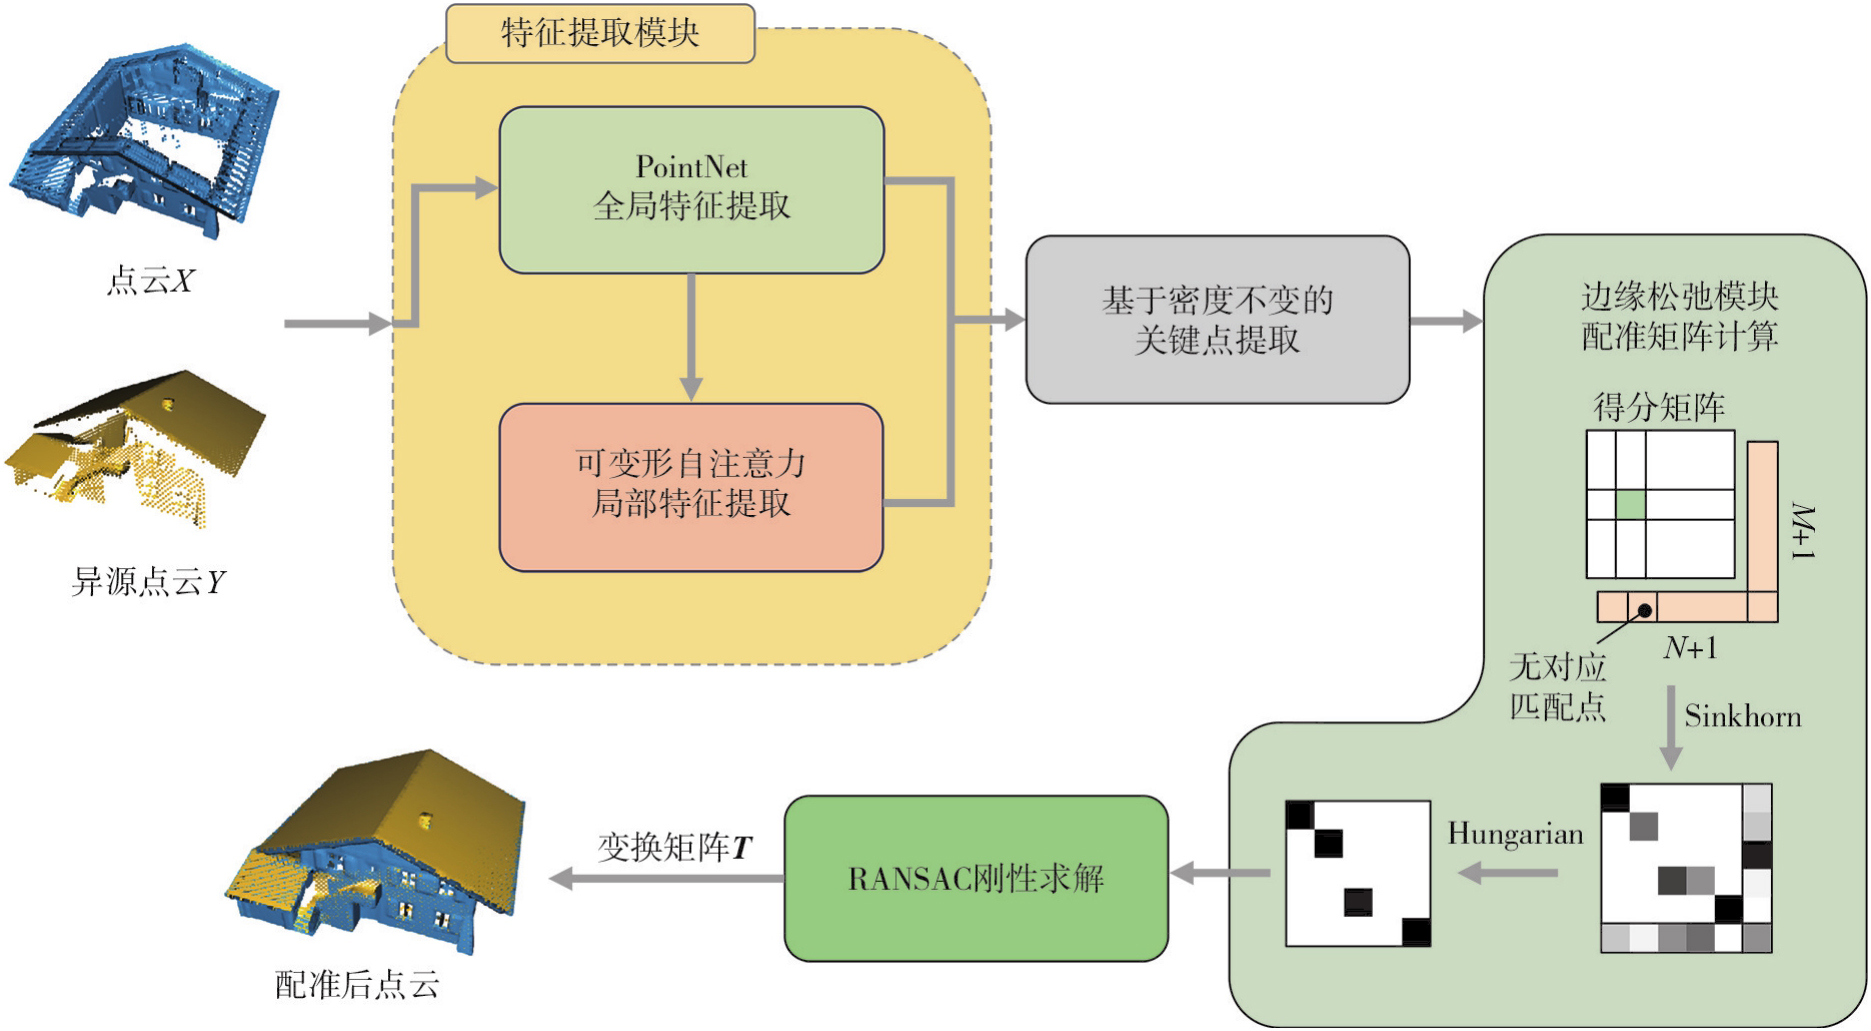
Fig. 2
Structure of the deformable self-attention module"
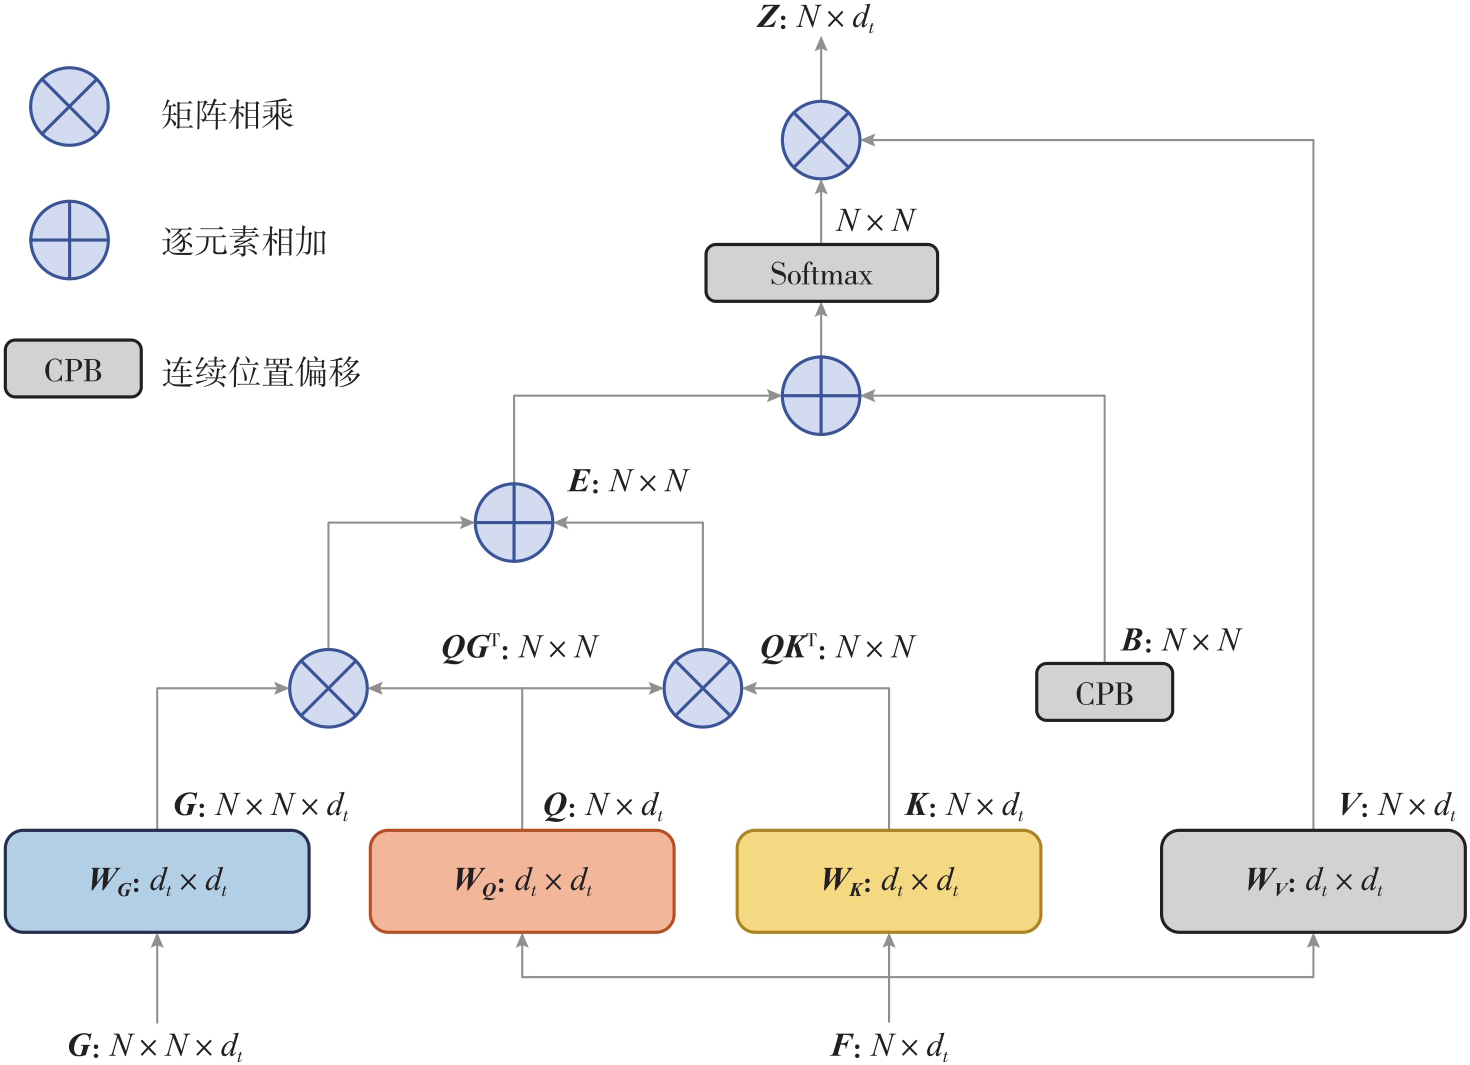
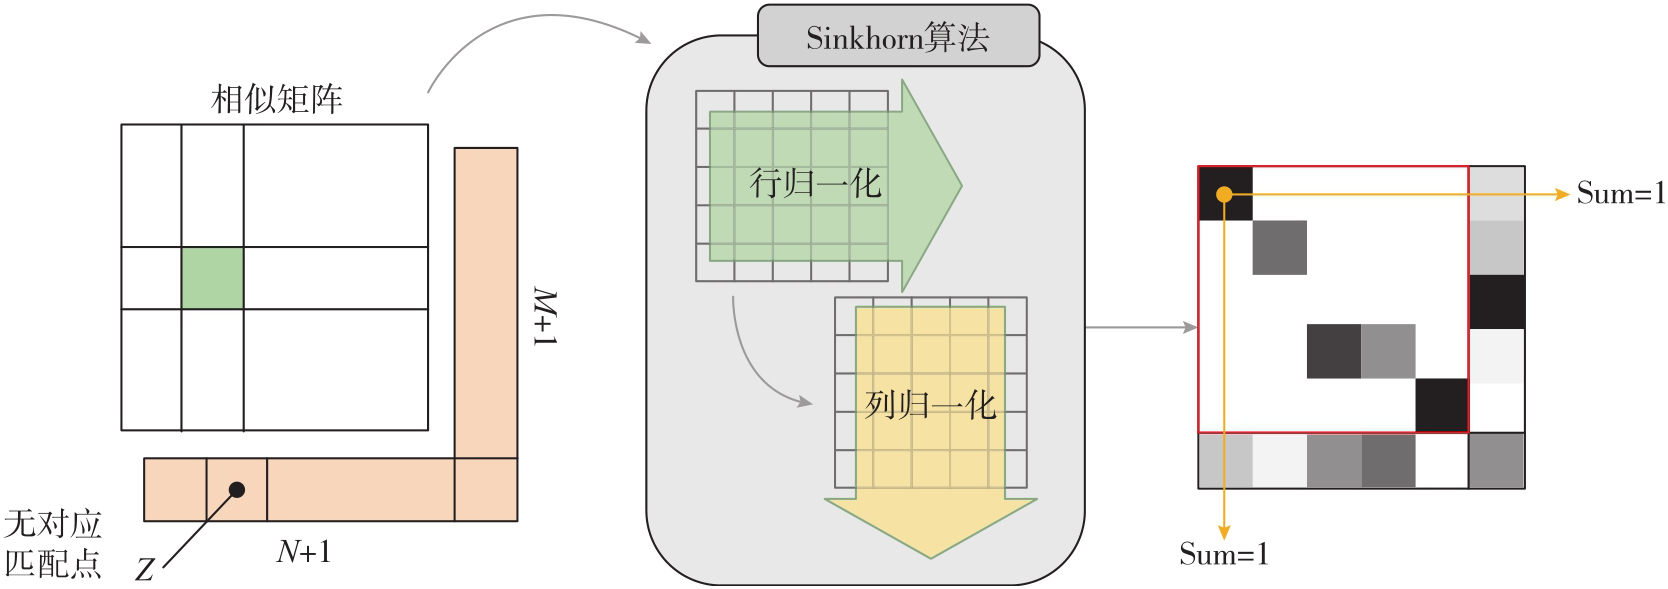
Fig. 3
Edge relaxation module architecture"
Tab. 1
Quantitative experimental results of the 3DMatch and 3DLoMatch dataset"
| 方法 | FMR | RR | IR | |||
|---|---|---|---|---|---|---|
| 3DMatch | 3DLoMatch | 3DMatch | 3DLoMatch | 3DMatch | 3DLoMatch | |
| PerfectMatch | 82.9 | 34.2 | 50.8 | 11.0 | 16.4 | 4.8 |
| D3Feat | 93.1 | 66.5 | 77.9 | 39.1 | 41.8 | 15.0 |
| CoFiNet | 98.3 | 82.6 | 87.0 | 61.0 | 52.2 | 26.9 |
| Predator | 96.5 | 75.3 | 86.6 | 58.1 | 49.3 | 25.8 |
| GeoTransformer | 97.8 | 88.7 | 91.1 | 73.0 | 85.7 | 58.3 |
| 本文方法 | 98.3 | 89.1 | 91.6 | 75.9 | 77.9 | 49.7 |
Fig. 4
Visualization of registration results on the 3DMatch and 3DLoMatch datasets"
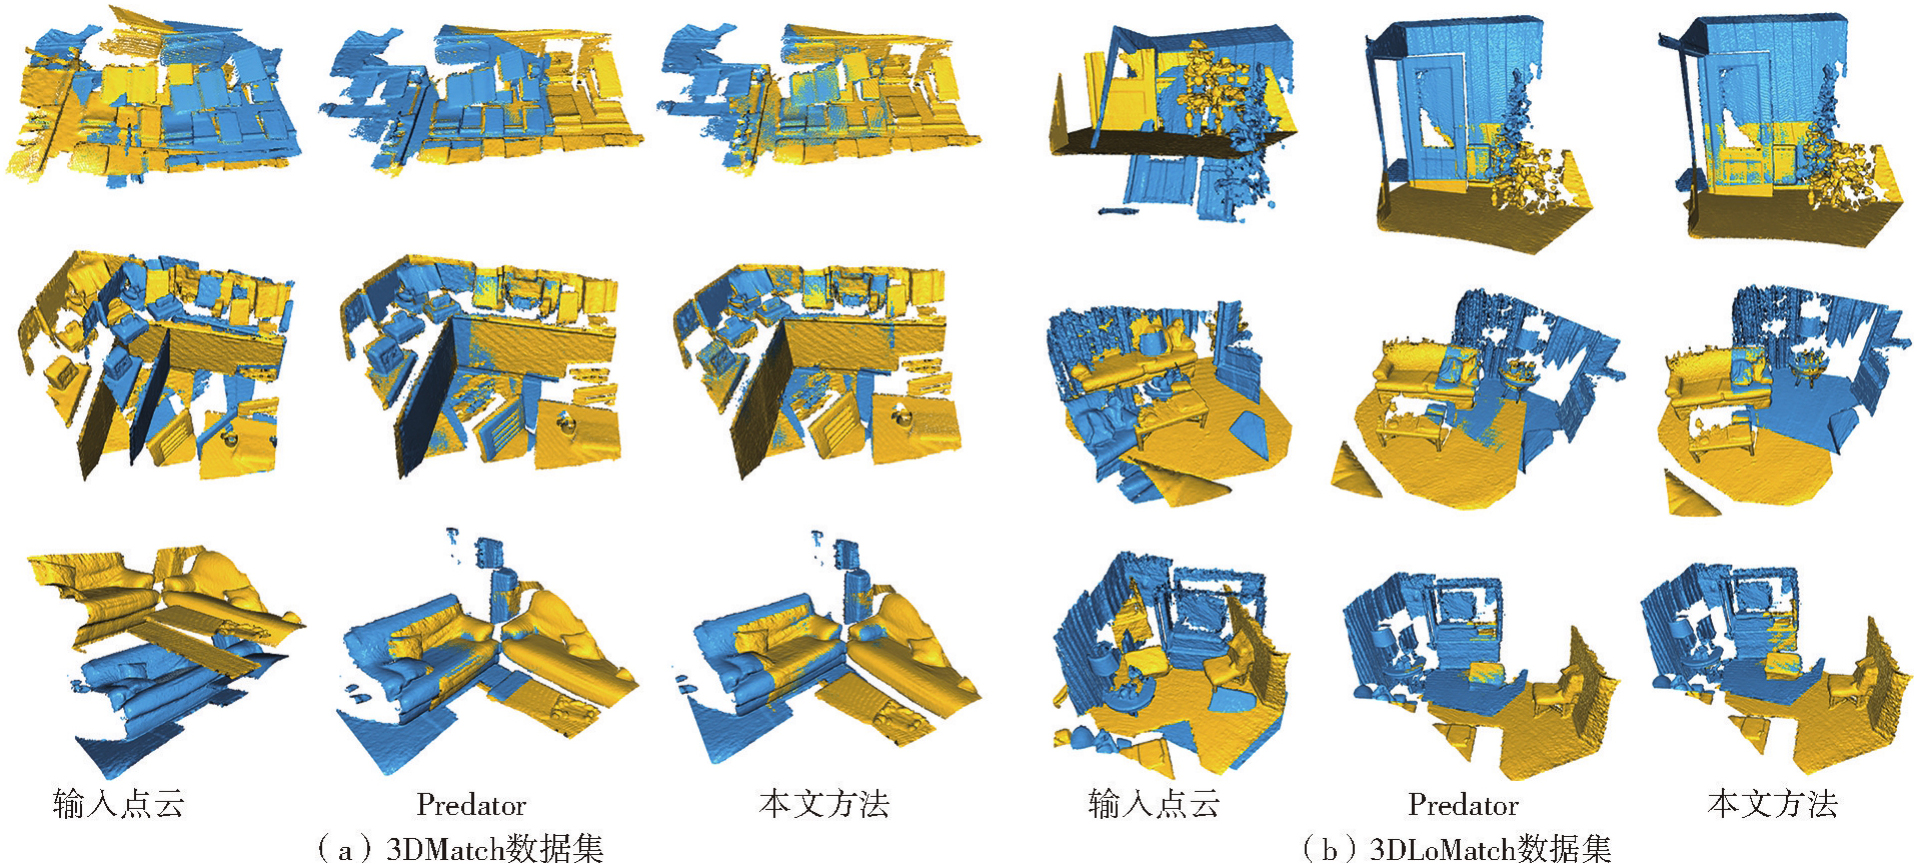
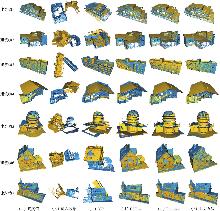
Fig. 5
Visualization of the registration results of heterogeneous building point clouds"

Tab. 2
Registration errors of heterogeneous building point clouds"
| 建筑物 | 方法 | 各向同性误差 | 各向异性误差 | ||
|---|---|---|---|---|---|
| R | t/m | R(x,y,z) | t(x,y,z)/m | ||
| 1 | ICP | 178.87° | 5.433 6 | 10.40°,1.51°,176.76° | 4.938 7,2.241 8,0.327 0 |
| D3Feat | 0.81° | 0.032 1 | 0.11°,0.69°,0.44° | 0.006 3,0.030 8,0.006 6 | |
| Predator | 0.46° | 0.035 8 | 0.31°,0.23°,0.32° | 0.000 9,0.035 6,0.003 8 | |
| 本文方法 | 0.18° | 0.015 1 | 0.10°,0.13°,0.09° | 0.006 4,0.011 9,0.006 7 | |
| 2 | ICP | 178.27° | 4.160 0 | 174.85°,36.21°,32.11° | 2.679 7,3.110 4,0.671 5 |
| D3Feat | 11.65° | 0.567 3 | 11.62°,1.71°,1.15° | 0.032 5,0.039 7,0.565 0 | |
| Predator | 0.46° | 0.010 3 | 0.30°,0.35°,0.08° | 0.001 3,0.000 6,0.010 2 | |
| 本文方法 | 1.15° | 0.051 1 | 0.33°,0.55°,1.00° | 0.041 5,0.005 9,0.029 3 | |
| 3 | ICP | 179.99° | 2.224 1 | 0.30°,0.34°,179.86° | 1.889 3,1.170 2,0.089 6 |
| D3Feat | 1.44° | 0.121 2 | 1.34°,0.51°,0.03° | 0.067 2,0.100 3,0.010 3 | |
| Predator | 0.76° | 0.063 3 | 0.00°,0.30°,0.69° | 0.006 0,0.062 6,0.007 2 | |
| 本文方法 | 0.29° | 0.036 7 | 0.13°,0.27°,0.02° | 0.028 8,0.016 3,0.015 8 | |
| 4 | ICP | 175.70° | 5.576 7 | 0.61°,2.68°,175.62° | 4.420 2,3.394 9,0.188 5 |
| D3Feat | 13.09° | 0.876 5 | 0.42°,12.52°,3.88° | 0.464 3,0.077 7,0.739 3 | |
| Predator | 1.85° | 0.126 3 | 1.30°,1.31°,0.34° | 0.017 5,0.059 5,0.110 0 | |
| 本文方法 | 1.23° | 0.068 4 | 0.93°,0.54°,0.70° | 0.000 1,0.041 0,0.054 8 | |
| 5 | ICP | 89.23° | 5.160 1 | 0.12°,1.67°,89.15° | 1.083 2,5.042 3,0.169 3 |
| D3Feat | 25.90° | 5.198 9 | 21.93°,7.67°,28.88° | 5.143 8,0.250 8,0.711 6 | |
| Predator | 0.94° | 0.105 6 | 0.36°,0.86°,0.11° | 0.002 5,0.105 5,0.003 6 | |
| 本文方法 | 0.61° | 0.042 4 | 0.26°,0.54°,0.04° | 0.001 2,0.042 1,0.004 5 | |
| 6 | ICP | 179.19° | 4.915 3 | 22.43°,61.71°,174.72° | 4.218 8,2.483 5,0.441 0 |
| D3Feat | 1.19° | 0.013 4 | 1.02°,0.65°,0.68° | 0.011 6,0.004 6,0.004 9 | |
| Predator | 0.99° | 0.050 4 | 0.66°,0.74°,0.42° | 0.048 1,0.005 5,0.013 9 | |
| 本文方法 | 0.52° | 0.017 0 | 0.20°,0.03°,0.41° | 0.010 7,0.010 7,0.007 9 | |
| 7 | ICP | 124.40° | 3.759 6 | 121.09°,32.56°,22.07° | 0.957 1,1.492 6,3.315 3 |
| D3Feat | 1.88° | 0.093 4 | 1.09°,1.26°,0.64° | 0.002 1,0.029 6,0.088 5 | |
| Predator | 0.96° | 0.036 8 | 0.84°,0.51°,0.14° | 0.002 8,0.003 8,0.036 5 | |
| 本文方法 | 1.57° | 0.033 5 | 1.04°,1.10°,0.76° | 0.010 8,0.003 4,0.031 5 | |
Tab. 3
Results of the ablation experiment"
| 方法 | 3DLoMatch RR/(%) | 自建异源建筑数据集 | |
|---|---|---|---|
| R/(°) | t/m | ||
| DSA-DI w/o可变形自注意力模块 | 71.6 | 0.92 | 0.044 |
| DSA-DI w/o密度不变模块 | 69.2 | 1.15 | 0.058 |
| DSA-DI w/o边缘松弛模块 | 72.3 | 0.87 | 0.043 |
| DSA-DI(完整模型) | 75.9 | 0.75 | 0.036 |
| [1] |
程昫, 葛亮, 张帆, 等. 倾斜摄影建筑物模型自动纹理重建[J]. 测绘学报, 2023, 52(9): 1528-1537. DOI: .
doi: 10.11947/j.AGCS.2023.20220165 |
|
Cheng Xu, Ge Liang, Zhang Fan, et al. Automated texture mapping of reality CSG building model with oblique aerial imagery[J]. Acta Geodaetica et Cartographica Sinica, 2023, 52(9): 1528-1537. DOI: .
doi: 10.11947/j.AGCS.2023.20220165 |
|
| [2] |
季顺平, 刘瑾, 高建, 等. 多视影像深度学习密集匹配三维重建智能框架[J]. 测绘学报, 2025, 54(9): 1633-1646. DOI: .
doi: 10.11947/j.AGCS.2025.20230306 |
|
Ji Shunping, Liu Jin, Gao Jian, et al. An intelligent 3D reconstruction framework via deep learning based multi-view image matching[J]. Acta Geodaetica et Cartographica Sinica, 2025, 54(9): 1633-1646. DOI: .
doi: 10.11947/j.AGCS.2025.20230306 |
|
| [3] | 谭金石, 祖为国, 刘丽. 激光扫描与倾斜摄影空地协同的建筑物三维模型构建方法[J]. 应用激光, 2023, 43(7): 107-115. |
| Tan Jinshi, Zu Weiguo, Liu Li. 3D construction method of buildings with laser scanning and oblique photography air-ground collaborating[J]. Applied Laser, 2023, 43(7): 107-115. | |
| [4] | Aiger D, Mitra N J, Cohen-Or D.4-points congruent sets for robust pairwise surface registration[J]. ACM Transactions on Graphics, 2008, 27(3): 1-10. |
| [5] | Fotsing C, Nziengam N, Bobda C. Large common plansets-4-points congruent sets for point cloud registration[J]. ISPRS International Journal of Geo-Information, 2020, 9(11): 647. |
| [6] | Xu Yusheng, Boerner Richard, Yao Wei, et al. Pairwise coarse registration of point clouds in urban scenes using voxel-based 4-planes congruent sets[J]. ISPRS Journal of Photogrammetry and Remote Sensing, 2019, 151: 106-123. |
| [7] | Biber P, Strasser W. The normal distributions transform: a new approach to laser scan matching[C]//Proceedings of 2003 IEEE/RSJ International Conference on Intelligent Robots and Systems. Las Vegas: IEEE, 2003: 2743-2748. |
| [8] | Magnusson M, Lilienthal A, Duckett T. Scan registration for autonomous mining vehicles using 3D-NDT[J]. Journal of Field Robotics, 2007, 24(10): 803-827. |
| [9] | Lu Jun, Liu Wei, Dong Donglai, et al. Point cloud registration algorithm based on NDT with variable size voxel[C]//Proceedings of the 34th Chinese Control Conference. Hangzhou: IEEE, 2015: 3707-3712. |
| [10] |
闫利, 谭骏祥, 刘华, 等. 融合遗传算法和ICP的地面与车载激光点云配准[J]. 测绘学报, 2018, 47(4): 528-536. DOI: .
doi: 10.11947/j.AGCS.2018.20170235 |
|
Yan Li, Tan Junxiang, Liu Hua, et al. Registration of TLS and MLS point cloud combining genetic algorithm with ICP[J]. Acta Geodaetica et Cartographica Sinica, 2018, 47(4): 528-536. DOI: .
doi: 10.11947/j.AGCS.2018.20170235 |
|
| [11] | Chen Yang, Medioni G. Object modelling by registration of multiple range images[J]. Image and Vision Computing, 1992, 10(3): 145-155. |
| [12] | Besl P J, McKay N D. Method for registration of 3-D shapes[C]//Proceedings of 1992 Sensor Fusion IV: Control Paradigms and Data Structures. Boston: SPIE, 1992: 586-606. |
| [13] | Lu Weixin, Wan Guowei, Zhou Yao, et al. DeepVCP: an end-to-end deep neural network for point cloud registration[C]//Proceedings of 2019 IEEE/CVF International Conference on Computer Vision. Seoul: IEEE, 2019: 12-21. |
| [14] | Qi Charleš R, Yi Li, Su Hao, et al. PointNet++: deep hierarchical feature learning on point sets in a metric space[J]. Advances in Neural Information Processing Systems, 2017, 30: 5099-5108. |
| [15] | Aoki Y, Goforth H, Srivatsan R A, et al. PointNetLK: robust & efficient point cloud registration using PointNet[C]//Proceedings of 2019 IEEE/CVF Conference on Computer Vision and Pattern Recognition. Long Beach: IEEE, 2019: 7156-7165. |
| [16] | Qi Charles R, Su Hao, Mo Kaichun, et al. PointNet: deep learning on point sets for 3D classification and segmentation[C]//Proceedings of 2017 IEEE Conference on Computer Vision and Pattern Recognition. Honolulu: IEEE, 2017: 652-660. |
| [17] | Wang Yue, Solomon Justin M. Deep closest point: learning representations for point cloud registration[C]//Proceedings of 2019 IEEE/CVF International Conference on Computer Vision. Seoul: IEEE, 2019: 3522-3531. |
| [18] | Wang Yue, Sun Yongbin, Liu Ziwei, et al. Dynamic graph CNN for learning on point clouds[J]. ACM Transactions on Graphics, 2019, 38(5): 1-12. |
| [19] | Yew Z J, Lee G H. RPM-net: robust point matching using learned features[C]//Proceedings of 2020 IEEE/CVF Conference on Computer Vision and Pattern Recognition. Seattle: IEEE, 2020: 11821-11830. |
| [20] | Huang Shengyu, Gojcic Zan, Usvyatsov Mikhail, et al. Predator: registration of 3D point clouds with low overlap[C]//Proceedings of 2021 IEEE/CVF Conference on Computer Vision and Pattern Recognition. Nashville: IEEE, 2021: 4265-4274. |
| [21] | Qin Zheng, Yu Hao, Wang Changjian, et al. GeoTransformer: fast and robust point cloud registration with geometric transformer[J]. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2023, 45(8): 9806-9821. |
| [22] | 孔煜, 熊风光, 张志强, 等. 基于深度位置感知Transformer的低重叠点云配准[J]. 计算机科学, 2025, 52(5): 199-211. |
| Kong Yu, Xiong Fengguang, Zhang Zhiqiang, et al. Low overlap point cloud registration method based on deep position-aware Transformer[J]. Computer Science, 2025, 52(5): 199-211. | |
| [23] | Xia Zhuofan, Pan Xuran, Song Shiji, et al. Vision transformer with deformable attention[C]//Proceedings of 2022 IEEE/CVF Conference on Computer Vision and Pattern Recognition. New Orleans: IEEE, 2022: 4784-4793. |
| [24] | Khan S, Naseer M, Hayat M, et al. Transformers in vision: a survey[J]. ACM Computing Surveys, 2022, 54(10s): 1-41. |
| [25] | Xiong Fengguang, Kong Yu, Xie Shuaikang, et al. Spatial deformable transformer for 3D point cloud registration[J]. Scientific Reports, 2024, 14: 5560. |
| [26] | Bai Xuyang, Luo Zixin, Zhou Lei, et al. D3Feat: joint learning of dense detection and description of 3D local features[C]//Proceedings of 2020 IEEE/CVF Conference on Computer Vision and Pattern Recognition. Seattle: IEEE, 2020: 6358-6366. |
| [27] | Zeng Andy, Song Shuran, Niebner Matthias, et al. 3DMatch: learning local geometric descriptors from RGB-D reconstructions[C]//Proceedings of 2017 IEEE Conference on Computer Vision and Pattern Recognition. Honolulu: IEEE, 2017: 1802-1811. |
| [28] | Liu Ze, Hu Han, Lin Yutong, et al. Swin transformer V2: scaling up capacity and resolution[C]//Proceedings of 2022 IEEE/CVF Conference on Computer Vision and Pattern Recognition. New Orleans: IEEE, 2022: 12009-12019. |
| [29] | Fu Kexue, Yuan Mingzhi, Wang Changwei, et al. Dual focus-attention transformer for robust point cloud registration[C]//Proceedings of 2025 IEEE/CVF Conference on Computer Vision and Pattern Recognition. Nashville: IEEE, 2025: 11769-11778. |
| [30] | 杜佳锦, 柏正尧, 刘旭珩, 等. 融合几何注意力和多尺度特征点云配准网络[J]. 计算机工程与应用, 2024, 60(12): 234-244. |
| Du Jiajin, Bai Zhengyao, Liu Xuheng, et al. Fusion of geometric attention and multi-scale feature network for point cloud registration[J]. Computer Engineering and Applications, 2024, 60(12): 234-244. | |
| [31] | Liu Quan, Zhu Hongzi, Zhou Yunsong, et al. Density-invariant features for distant point cloud registration[C]//Proceedings of 2023 IEEE/CVF International Conference on Computer Vision. Paris: IEEE, 2023: 18169-18179. |
| [32] | Gojcic Zan, Zhou Caifa, Wegner Jan D, et al. The perfect match: 3D point cloud matching with smoothed densities[C]//Proceedings of 2019 IEEE/CVF Conference on Computer Vision and Pattern Recognition. Long Beach: IEEE, 2019: 5540-5549. |
| [33] | Yu Hao, Li Fu, Saleh Mahdi, et al. CoFiNet: reliable coarse-to-fine correspondences for robust point cloud registration[C]//Proceedings of 2021 Advances in Neural Information Processing Systems. Virtual: Curran Associates, Inc., 2021: 23872-23884. |
| [1] | Pengcheng WEI, Guiyu JIANG, Hangyi SHEN, Haifeng HUANG, Rongling ZHANG. Millimeter-level surface deformation detection method based on high-precision laser point cloud registration [J]. Acta Geodaetica et Cartographica Sinica, 2026, 55(5): 866-880. |
| [2] | ZHANG Guangyun, HAN Yi, ZHANG Rongting, LI Mingfeng, JI Wenlai. A spatial consistency-based point cloud registration method for the same platform [J]. Acta Geodaetica et Cartographica Sinica, 2023, 52(5): 789-797. |
| [3] | LI Haoran, MEI Tiancan, GAO Zhi. 3D face reconstruction based on global ICP and improved Poisson [J]. Acta Geodaetica et Cartographica Sinica, 2023, 52(3): 454-463. |
| [4] | LI Jiayuan, ZHANG Yongjun, AI Mingyao, HU Qingwu. Scale-adaptive Cauchy robust estimation based on progressive optimization and its applications [J]. Acta Geodaetica et Cartographica Sinica, 2023, 52(1): 61-70. |
| [5] | SUN Xiliang, GUAN Hongcan, SU Yanjun, XU Guangcai, GUO Qinghua. A tightly coupled SLAM method for precise urban mapping [J]. Acta Geodaetica et Cartographica Sinica, 2021, 50(11): 1585-1593. |
| [6] | LI Shuaixin, LI Jiuren, TIAN Bin, CHEN Long, WANG Li, LI Guangyun. A laser SLAM method for unmanned vehicles in point cloud degenerated tunnel environments [J]. Acta Geodaetica et Cartographica Sinica, 2021, 50(11): 1487-1499. |
| [7] | YAN Li, TAN Junxiang, LIU Hua, CHEN Changjun. Registration of TLS and MLS Point Cloud Combining Genetic Algorithm with ICP [J]. Acta Geodaetica et Cartographica Sinica, 2018, 47(4): 528-536. |
| [8] | ZHANG Haixiao, ZHONG Ruofei, SUN Haili. External Parameter Calibration Method of Vehicle Laser Scanning System Based on Planar Features [J]. Acta Geodaetica et Cartographica Sinica, 2018, 47(12): 1640-1649. |
| [9] | SHENG Qinghong, CHEN Shuwen, LIU Jianfeng, WANG Huinan. LiDAR Point Cloud Registration Based on Plücker Line [J]. Acta Geodaetica et Cartographica Sinica, 2016, 45(1): 58-64. |
| [10] | LI Cailin, GUO Baoyun, JI Zheng. Global Optimization and Whole Registration Algorithm of Multi-view 3D Laser Point Cloud [J]. Acta Geodaetica et Cartographica Sinica, 2015, 44(2): 183-189. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
