Acta Geodaetica et Cartographica Sinica ›› 2026, Vol. 55 ›› Issue (9): 1666-1678.doi: 10.11947/j.AGCS.2026.20260161
• Cartography and Geographic Information • Previous Articles Next Articles
Youneng Su1( ), Zhiyong Lin1(), Yi Liu2, Fubing Zhang3, Xinming Zhu2, Pengfei Pan1
Received:2026-04-29
Revised:2026-08-27
Online:2026-10-28
Published:2026-10-28
Contact:
Zhiyong Lin
E-mail:youneng_2000@163.com;zhylin@whu.edu.cn
About author:Su Youneng (2000—), male, PhD candidate, majors in visual navigation and localization. E-mail: youneng_2000@163.com
Supported by:CLC Number:
Youneng Su, Zhiyong Lin, Yi Liu, Fubing Zhang, Xinming Zhu, Pengfei Pan. Building semantics-driven UAV geographic-matching localization in GNSS-denied urban environments[J]. Acta Geodaetica et Cartographica Sinica, 2026, 55(9): 1666-1678.
Fig. 1
Research framework of this paper"
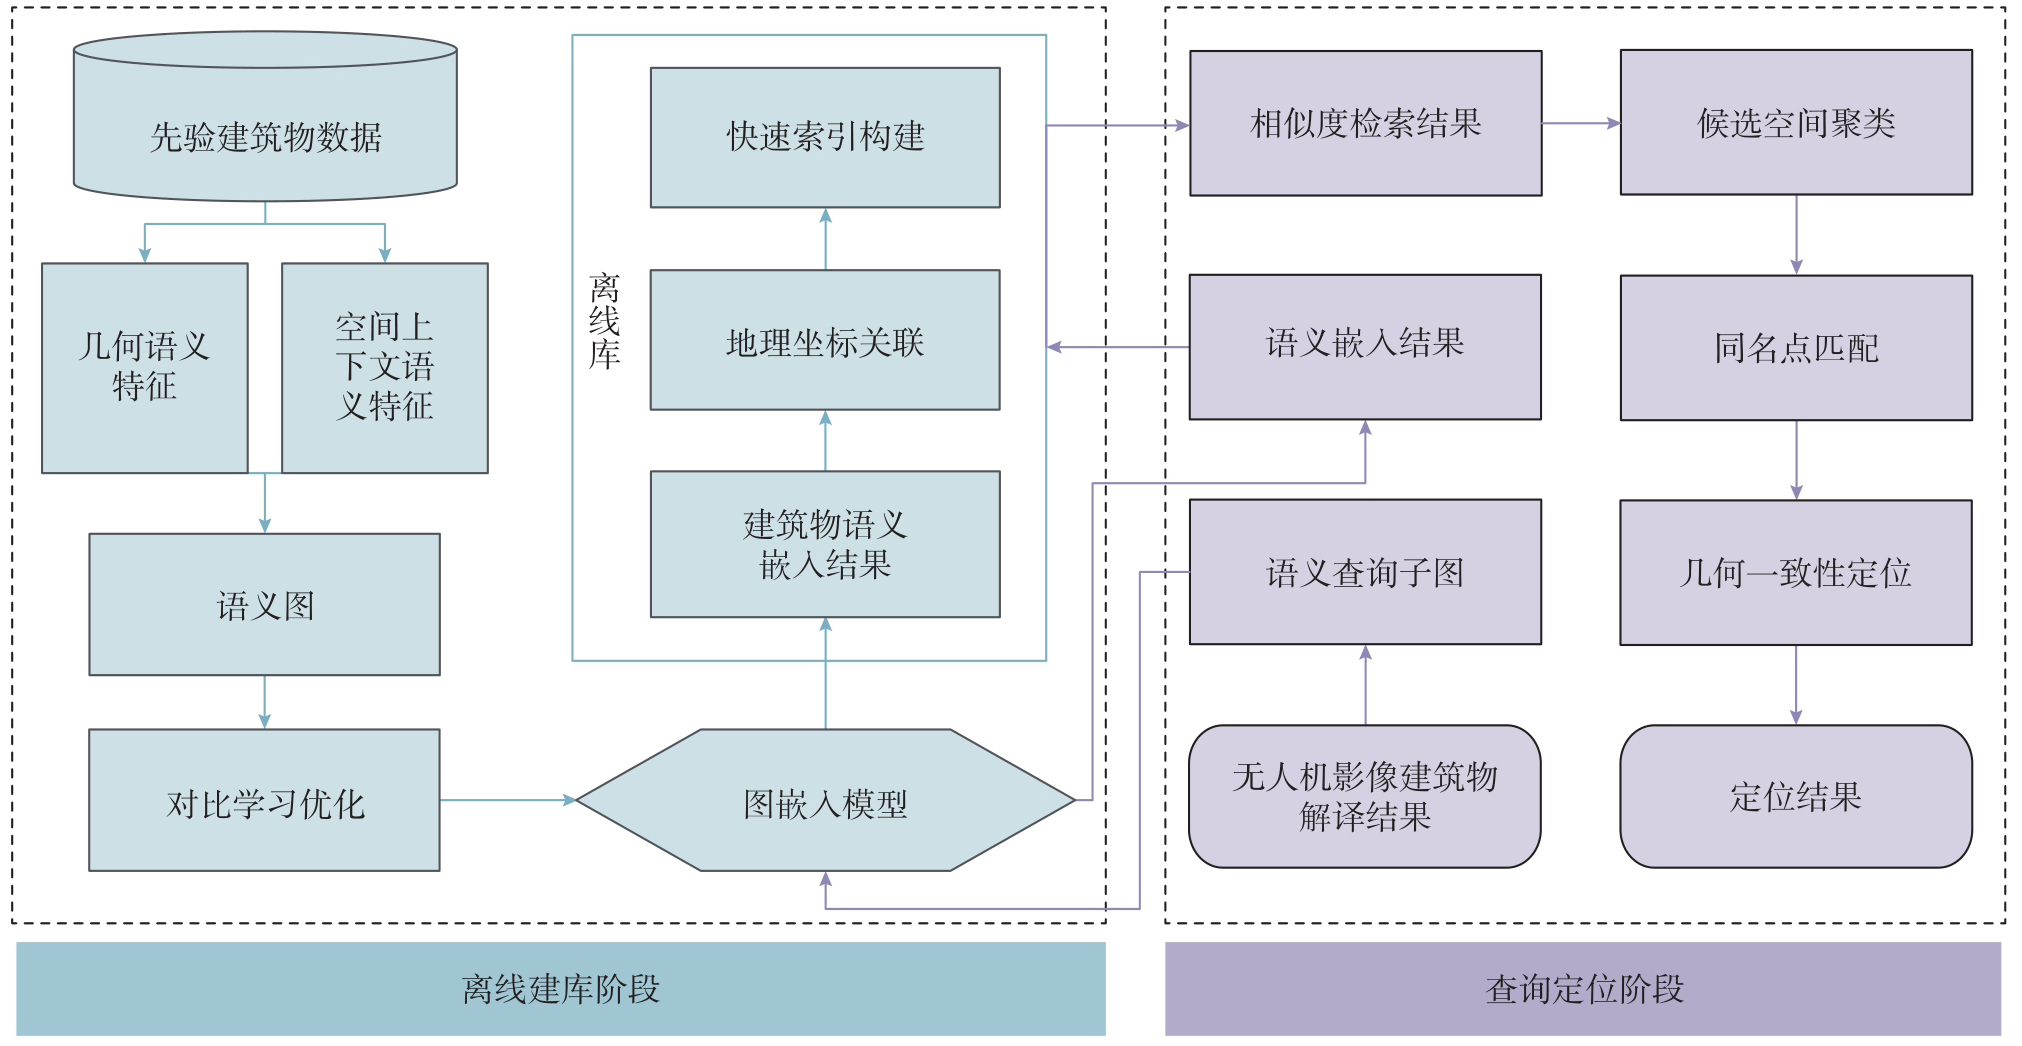
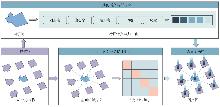
Fig. 2
Process of extracting geometric features from buildings"

Tab. 1
Geometric semantic features"
| 特征名称 | 公式 | 取值范围 | 含义 |
|---|---|---|---|
| 圆形度 | C=4πS/L2 | (0,1] | 建筑物形状与圆的接近程度 |
| 偏心率 | E=a/b | [1,∞) | 建筑物拉长程度 |
| 矩形度 | R=S/(a×b) | (0,1] | 建筑物与最小外接矩形的规整性 |
| 凹度 | V=S/Sconv | (0,1] | 建筑物凹陷程度 |
| 尺寸 | A=a | [0,∞) | 建筑物绝对尺寸(长边长度) |
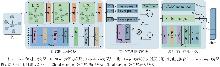
Fig. 3
Graph encoder architecture"

Tab. 2
Data augmentation operator"
| 算子 | 描述 |
|---|---|
| 节点丢弃 | 以概率pnode随机丢弃部分节点 |
| 特征丢弃 | 以概率pfeat将节点特征向量某些维度随机置零 |
| 边丢弃 | 以概率pedge随机丢弃部分边(自环除外) |
Tab. 3
Test set quantity distribution"
| 测试集 | 建筑物数量 | 定位测试窗口内建筑物数量 | ||
|---|---|---|---|---|
| 最小值 | 最大值 | 均值 | ||
| 同源测试集 | 13 385 | 5 | 103 | 13.39 |
| 异源测试集 | 17 800 | 6 | 113 | 17.80 |
Tab. 4
Localization performance comparison on homologous test set"
| 方法 | EffTop5/(%) |  | P20/(%) | P50/(%) | TPQ/s |
|---|---|---|---|---|---|
| GAT | 96.70 | 6.47 | 85.20 | 94.40 | 1.624 |
| GCN | 94.30 | 6.61 | 84.20 | 91.40 | 1.075 |
| GIN | 93.70 | 5.41 | 86.50 | 91.80 | 1.119 |
| GPS | 74.80 | 39.11 | 32.80 | 57.00 | 1.313 |
| GraphSAGE | 97.80 | 2.90 | 95.90 | 97.20 | 1.038 |
| NASC-GCN | 96.50 | 4.50 | 91.10 | 95.30 | 1.398 |
| Polynormer | 96.10 | 6.66 | 86.80 | 93.90 | 1.508 |
| SGFormer | 97.80 | 3.04 | 95.40 | 97.30 | 1.393 |
| VISNet | 96.10 | 6.68 | 86.20 | 93.70 | 1.277 |
| 本文方法 | 99.60 | 0.74 | 98.30 | 98.40 | 0.938 |
Tab. 5
Localization performance comparison on heterogeneous test set"
| 方法 | EffTop5/(%) |  | P20/(%) | P50/(%) | TPQ/s |
|---|---|---|---|---|---|
| GAT | 81.80 | 13.86 | 58.00 | 76.30 | 1.162 |
| GCN | 73.30 | 19.12 | 51.20 | 68.70 | 1.594 |
| GIN | 65.90 | 18.81 | 51.20 | 66.10 | 1.124 |
| GPS | 51.90 | 62.85 | 13.90 | 35.20 | 1.171 |
| GraphSAGE | 80.60 | 8.81 | 63.30 | 74.90 | 1.133 |
| NASC-GCN | 79.70 | 10.83 | 59.40 | 71.40 | 1.134 |
| Polynormer | 79.70 | 12.24 | 60.90 | 75.80 | 1.143 |
| SGFormer | 80.60 | 8.48 | 64.30 | 74.90 | 1.139 |
| VISNet | 78.10 | 13.36 | 58.90 | 73.10 | 1.159 |
| 本文方法 | 82.40 | 4.13 | 77.00 | 83.00 | 0.957 |
Tab. 6
Performance comparison of ablation experiments in the training stage"
| 数据集 | 编号 | P20/(%) |  |
|---|---|---|---|
| 同源数据集 | A1 | 84.20 | 6.61 |
| A2 | 95.10 | 1.65 | |
| A3 | 85.30 | 3.85 | |
| A4 | 86.70 | 2.80 | |
| A5 | 98.30 | 0.74 | |
| 异源数据集 | A1 | 51.20 | 19.12 |
| A2 | 58.70 | 9.91 | |
| A3 | 54.60 | 13.69 | |
| A4 | 55.80 | 11.14 | |
| A5 | 77.00 | 4.13 |
Tab. 7
Performance comparison of ablation experiments in the online localization stage"
| 数据集 | 编号 | P20/(%) |  |
|---|---|---|---|
| 同源数据集 | B1 | 41.50 | 23.76 |
| B2 | 36.10 | 26.05 | |
| B3 | 38.60 | 21.12 | |
| B4 | 98.30 | 0.74 | |
| 异源数据集 | B1 | 14.40 | 50.17 |
| B2 | 12.30 | 50.99 | |
| B3 | 12.50 | 49.76 | |
| B4 | 77.00 | 4.13 |
Tab. 8
Localization performance comparison on generalization test"
| 方法 | EffTop5/(%) |  | P20/(%) | P50/(%) |
|---|---|---|---|---|
| GraphSAGE | 98.80 | 4.49 | 95.00 | 98.00 |
| SGFormer | 98.40 | 4.80 | 94.80 | 97.50 |
| 本文方法 | 99.20 | 1.08 | 99.70 | 99.90 |
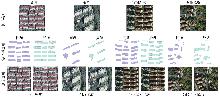
Fig. 4
Case results"
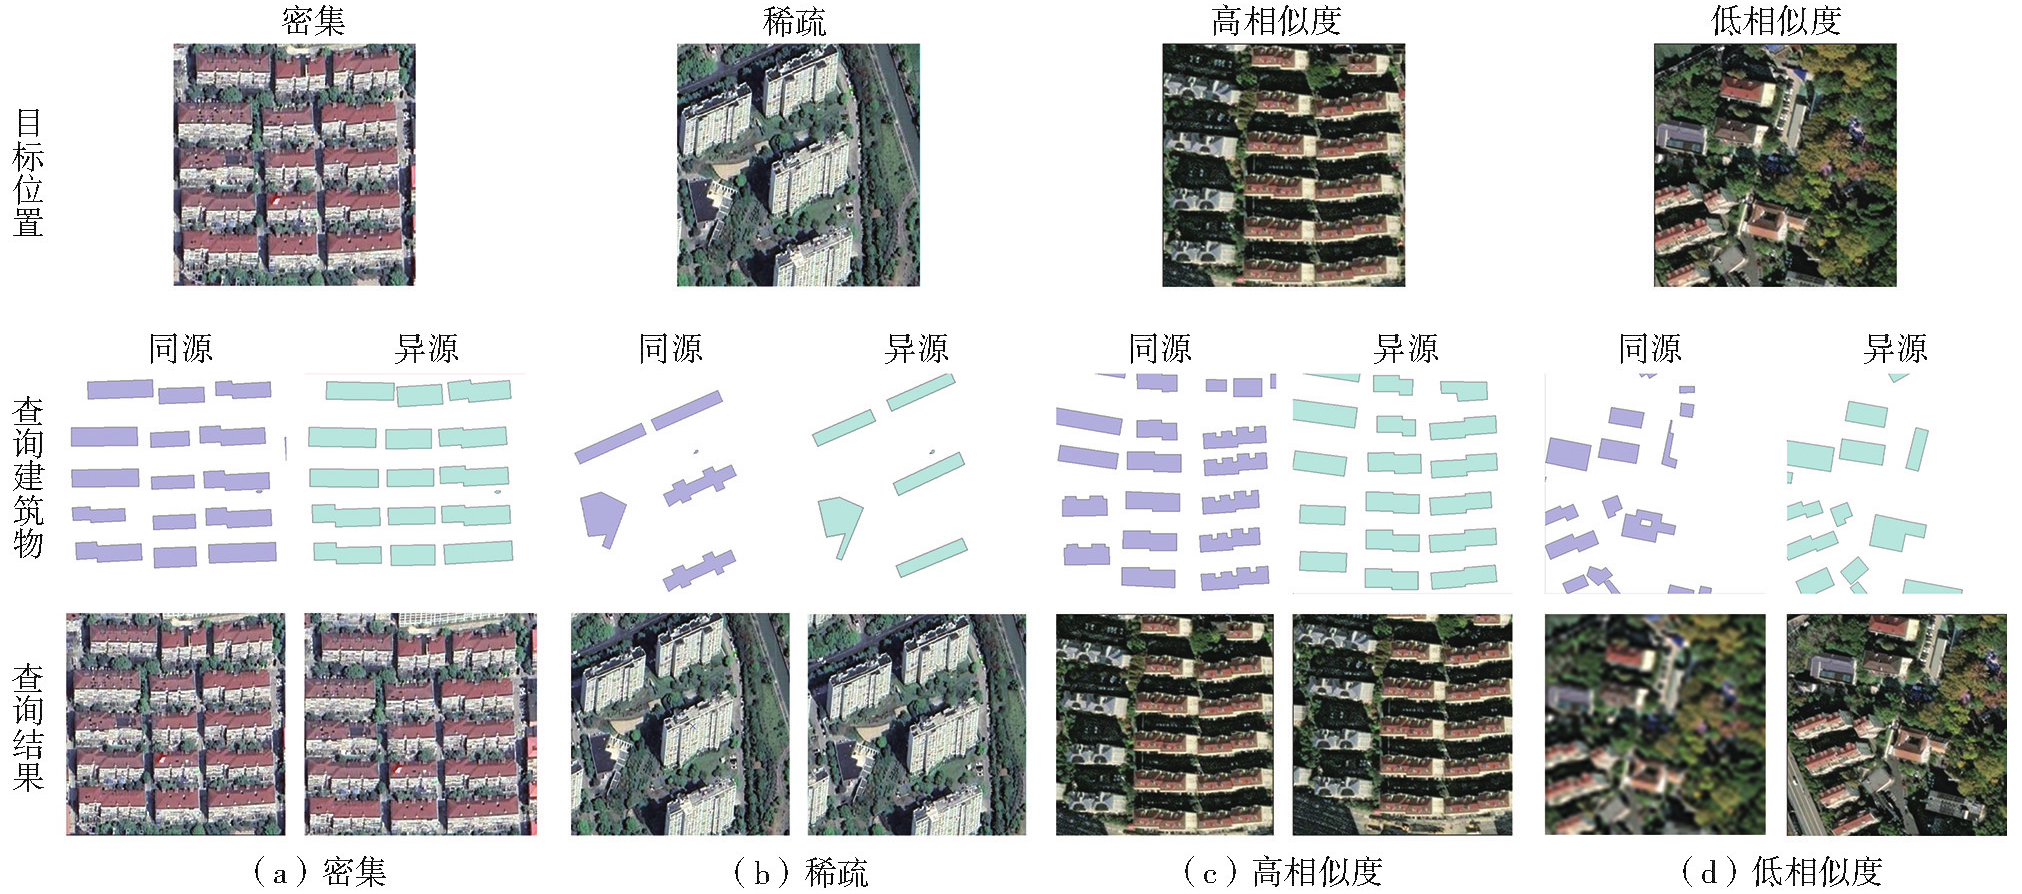
Fig. 5
Parameter sensitivity analysis"
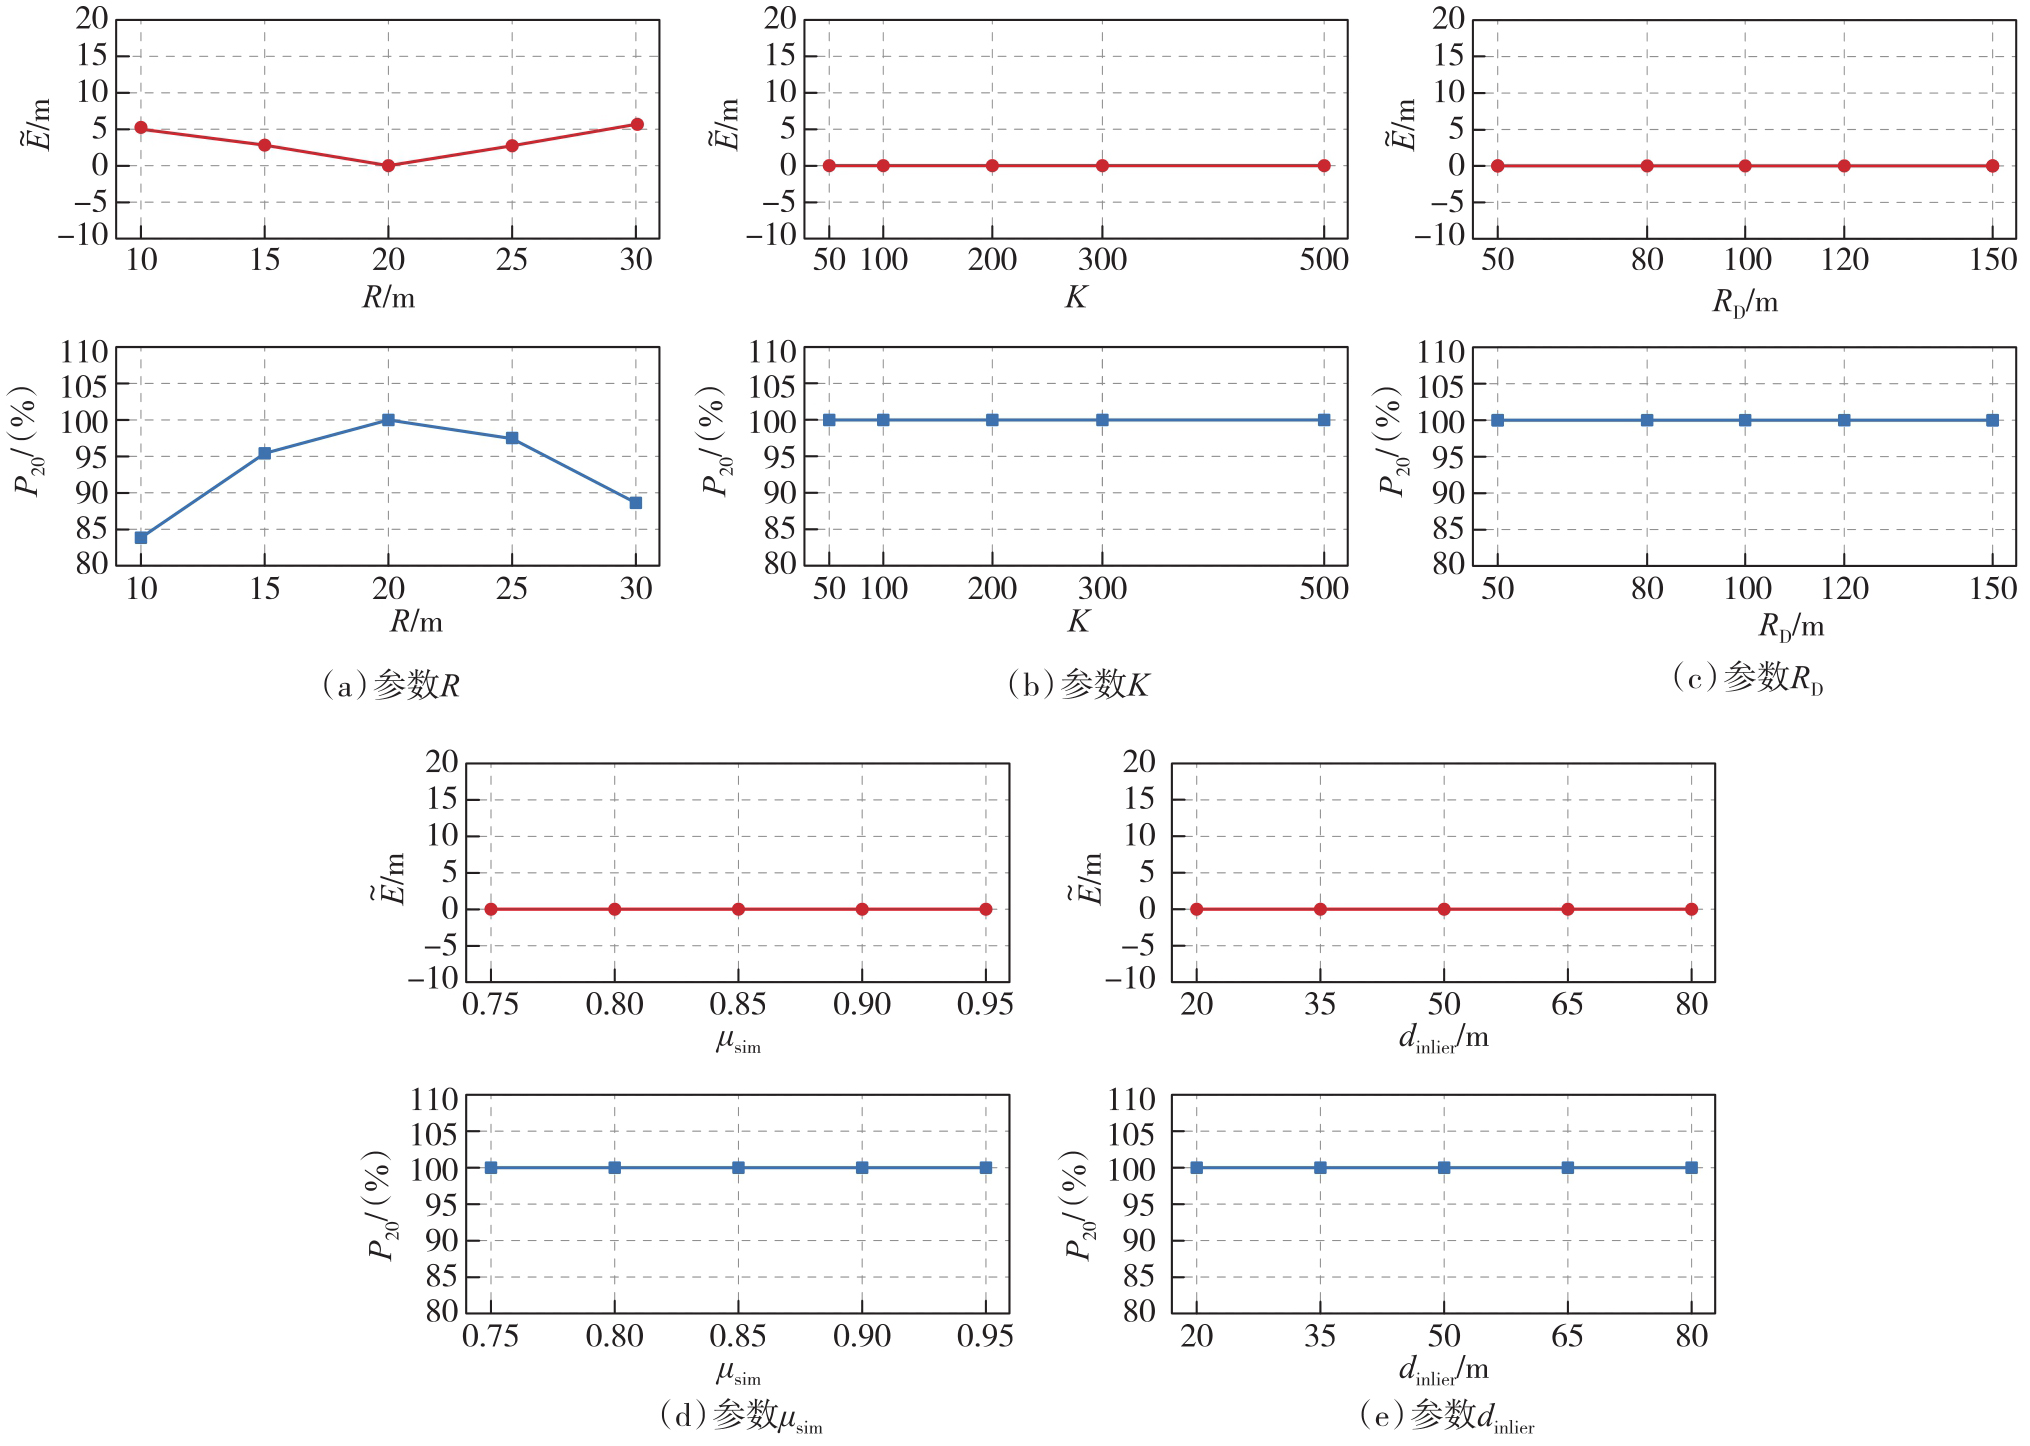
Fig. 6
Analysis results on the robustness of building silhouettes"
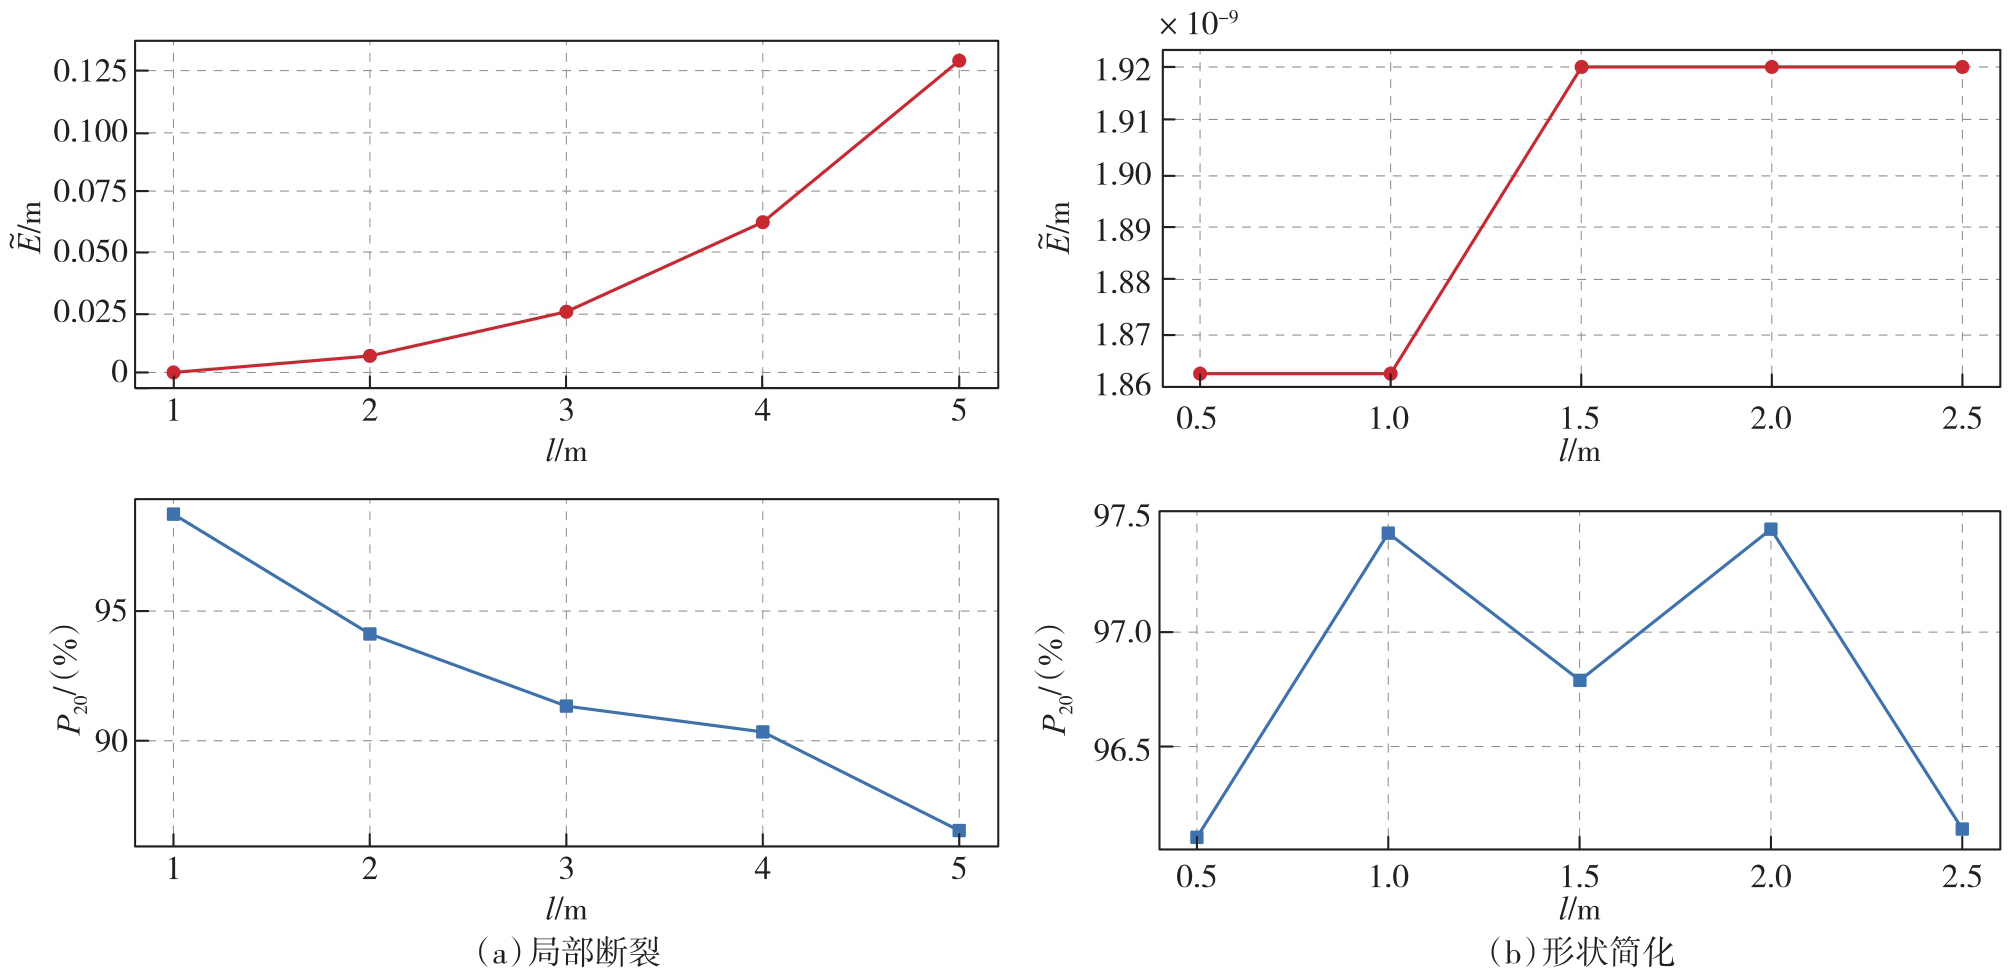
Tab. 9
Localization performance of the model under different density of buildings"
| 建筑数量 | P20/(%) |  |
|---|---|---|
| 1 | 2.65 | 71.92 |
| 2 | 75.75 | 4.71×10⁻¹ |
| 3 | 91.80 | 5.59×10⁻⁹ |
| 4 | 93.33 | 3.73×10⁻⁹ |
| 5 | 100.00 | 1.92×10⁻⁹ |
Tab. 10
Comparison of positioning performance"
| 方法 | P20/(%) |  |
|---|---|---|
| 纯几何特征检索 | 39.00 | 24.860 |
| 本文方法 | 98.30 | 0.938 |
| [1] | Li Wei, Talha M, Chen Leilei, et al. Sustainable road infrastructure operation via intelligent UAV inspection systems: trends, challenges, and research opportunities[J]. Automation in Construction, 2026, 187: 106909. |
| [2] | Guo J R, Zhou Y Y, Burlion L, et al. Autonomous UAV last-mile delivery in urban environments: a survey on deep learning and reinforcement learning solutions[J]. Control Engineering Practice, 2025, 165: 106491. |
| [3] | Abdulrashid I, Khalafalla M, Kadiyala N S, et al. AI-driven decision support for disaster management and humanitarian logistics: models, applications, and research challenges[J]. Transportation Research Part E: Logistics and Transportation Review, 2026, 210: 104821. |
| [4] | Gudavalli C, Mohammed T M, Yadav A, et al. Wrivinder: towards spatial intelligence for geo-locating ground images onto satellite imagery[C]//Proceedings of 2026 IEEE/CVF Conference on Computer Vision and Pattern Recognition. Denver: IEEE, 2026. |
| [5] | 李红光, 刘泽伟, 李新军, 等. 基于深度学习的无人机视觉定位技术最新进展[J/OL]. 航空学报, 2026-03-17. https://link.cnki.net/urlid/11.1929.V.20260316.2031.014. |
| Li Hongguang, Liu Zewei, Li Xinjun, et al. The latest advances in UAV visual positioning technology based on deep learning[J/OL]. Acta Aeronautica et Astronautica Sinica, 2026-03-17. https://link.cnki.net/urlid/11.1929.V.20260316.2031.014. | |
| [6] | Liu Kejia, Zhou Haoyang, Xu Ruoyu, et al. Beyond matching to tiles: bridging unaligned aerial and satellite views for vision-only UAV navigation[PP/OL]. V3. arXiv (2026-04-11) [2026-05-01]. https://arxiv.org/pdf/2603.22153. |
| [7] | 赵璐颖, 周杨, 胡校飞, 等. 跨视角图像地理定位研究综述[J]. 地球信息科学学报, 2025, 27(10): 2293-2315. |
| Zhao Luying, Zhou Yang, Hu Xiaofei, et al. A review of cross-view image geolocalization research[J]. Journal of Geo-information Science, 2025, 27(10): 2293-2315. | |
| [8] | Zhu S, Yang T, Chen C. VIGOR: cross-view image geo-localization beyond one-to-one retrieval[C]//Proceedings of 2021 IEEE/CVF Conference on Computer Vision and Pattern Recognition. Nashville: IEEE, 2021: 5316-5325. |
| [9] | Padilha R, Salem T, Workman S, et al. Content-aware detection of temporal metadata manipulation[J]. IEEE Transactions on Information Forensics and Security, 2022, 17: 1316-1327. |
| [10] | 秦剑琪, 蓝朝桢, 崔志祥, 等. 一种面向无人机绝对定位的卫星基准影像检索方法[J]. 武汉大学学报(信息科学版), 2023, 48(3): 368-376. |
| Qin Jianqi, Lan Chaozhen, Cui Zhixiang, et al. A satellite reference image retrieval method for unmanned aerial vehicle absolute positioning[J]. Geomatics and Information Science of Wuhan University, 2023, 48(3): 368-376. | |
| [11] | 于瀚洋, 蓝朝桢, 王龙号, 等. 多模态遥感影像匹配的深度学习研究进展与趋势[J]. 地球信息科学学报, 2025, 27(8): 1896-1919. |
| Yu Hanyang, Lan Chaozhen, Wang Longhao, et al. Research advances and development trends of deep learning methods for multimodal remote sensing image matching[J]. Journal of Geo-information Science, 2025, 27(8): 1896-1919. | |
| [12] |
苏友能, 徐青, 孙群, 等. 邻近边约束下的建筑物自动合并方法[J]. 测绘学报, 2025, 54(3): 563-576. DOI: .
doi: 10.11947/j.AGCS.2025.20240138 |
|
Su Youneng, Xu Qing, Sun Qun, et al. A method for automatic buildings aggregation constrained by proximity edges[J]. Acta Geodaetica et Cartographica Sinica, 2025, 54(3): 563-576. DOI: .
doi: 10.11947/j.AGCS.2025.20240138 |
|
| [13] | Su Youneng, Xu Qing, Zhu Xinming, et al. Automatic functional classification of buildings supported by a POI semantic characterization knowledge graph[J]. ISPRS International Journal of Geo-Information, 2024, 13(8): 285. |
| [14] |
高晓蓉, 闫浩文, 禄小敏. 多尺度地图空间居民地语义相似度计算方法[J]. 测绘学报, 2022, 51(1): 95-103. DOI: .
doi: 10.11947/j.AGCS.2022.20210074 |
|
Gao Xiaorong, Yan Haowen, Lu Xiaomin. Semantic similarity measurement for building polygon aggregation in multi-scale map space[J]. Acta Geodaetica et Cartographica Sinica, 2022, 51(1): 95-103. DOI: .
doi: 10.11947/j.AGCS.2022.20210074 |
|
| [15] |
刘慧敏, 胡文柯, 唐建波, 等. 顾及功能语义特征的建筑物空间分布模式识别方法[J]. 测绘学报, 2020, 49(5): 622-631. DOI: .
doi: 10.11947/i.AGCS.2020.20190222 |
|
Liu Huimin, Hu Wenke, Tang Jianbo, et al. A method for recognizing building clusters by considering functional features of buildings[J]. Acta Geodaetica et Cartographica Sinica, 2020, 49(5): 622-631. DOI: .
doi: 10.11947/i.AGCS.2020.20190222 |
|
| [16] | Yan Xiongfeng, Ai Tinghua, Yang Min, et al. Graph convolutional autoencoder model for the shape coding and cognition of buildings in maps[J]. International Journal of Geographical Information Science, 2021, 35(3): 490-512. |
| [17] | Wang Haitao, Xu Yongyang, Hu Anna, et al. Building pattern recognition by using an edge-attention multi-head graph convolutional network[J]. International Journal of Geographical Information Science, 2025, 39(4): 732-757. |
| [18] | Zhang Pengxin, Yang Min, Yang Taiyang, et al. Using knowledge graph embeddings and meta-path transformers for geographic context-aware predictions of building functions[J]. International Journal of Geographical Information Science, 2026, 40(7): 2324-2357. |
| [19] | Su Youneng, Xu Qing, Zhu Xinming, et al. Automatic building aggregation supported by knowledge graph[J]. Transactions in GIS, 2025, 29(2): e70007. |
| [20] |
孙壮, 刘坡, 翟亮, 等. 一种基于三分支注意力网络的面状地理实体自监督匹配方法[J]. 测绘学报, 2026, 55(1): 169-180. DOI: .
doi: 10.11947/j.AGCS.2026.20250296 |
|
Sun Zhuang, Liu Po, Zhai Liang, et al. A self-supervised matching method for polygonal geographic entity based on a three-branch attention network[J]. Acta Geodaetica et Cartographica Sinica, 2026, 55(1): 169-180. DOI: .
doi: 10.11947/j.AGCS.2026.20250296 |
|
| [21] |
张付兵, 孙群, 马京振, 等. 融合全局和局部特征的建筑物形状智能分类方法[J]. 测绘学报, 2024, 53(9): 1842-1852. DOI: .
doi: 10.11947/j.AGCS.2024.20240040 |
|
Zhang Fubing, Sun Qun, Ma Jingzhen, et al. An intelligent classification method for building shape based on fusion of global nd local features[J]. Acta Geodaetica et Cartographica Sinica, 2024, 53(9): 1842-1852. DOI: .
doi: 10.11947/j.AGCS.2024.20240040 |
|
| [22] | Kipf T N, Welling M. Semi-supervised classification with graph convolutional networks[PP/OL]. V4. arXiv (2017-02-22) [2026-05-01]. https://arxiv.org/pdf/1609.02907. |
| [23] | Velickovic P, Cucurull G, Casanova A, et al. Graph attention networks[C]//Proceedings of the 6th International Conference on Learning Representations. Vancouver: ICLR, 2018. |
| [24] | Hamilton W L, Ying R, Leskovec J. Inductive representation learning on large graphs[C]//Proceedings of 2017 Advances in Neural Information Processing Systems. Red Hood: Curran Associates, Inc., 2017. |
| [25] | Xu K, Hu W, Leskovec J, et al. How powerful are graph neural networks?[PP/OL]. V3. arXiv (2019-02-22) [2026-05-01]. https://arxiv.org/pdf/1810.00826. |
| [26] | Rampášek L, Galkin M, Dwivedi V P, et al. Recipe for a general, powerful, scalable graph transformer[C]//Proceedings of 2022 Advances in Neural Information Processing Systems. Red Hood: Curran Associates, Inc., 2022: 14501-14515. |
| [27] | Wu Qitian, Zhao Wentao, Yang Chenxiao, et al. SGFormer: simplifying and empowering transformers for large-graph representations[C]//Proceedings of 2023Advances in Neural Information Processing Systems. Red Hood: Curran Associates, Inc., 2023: 64753-64773. |
| [28] | Deng Chenhui, Yue Zichao, Zhang Zhiru. Polynormer: polynomial-expressive graph transformer in linear time[C]//Proceedings of the 12th International Conference on Learning Representations. Vienna: ICLR, 2024. |
| [29] | Wang Y, Li S, He X, et al. ViSNet: an equivariant geometry-enhanced graph neural network with vector-scalar interactive message passing for molecules[PP/OL]. V3. arXiv (2023-08-16) [2026-05-01]. https://arxiv.org/pdf/2210.16518. |
| [30] | Sancak K, Balin M F, Çatalyürek Ü V. Do we really need complicated graph learning models? A simple but effective baseline[C]//Proceedings of the 3rd Learning on Graphs Conference. Suzhou: PMLR, 2024. |
| [1] | Qingdong WANG, Tengfei WANG, Li ZHANG. Cross-modal contrastive masked autoencoder pre-training for 3D real-scene point cloud [J]. Acta Geodaetica et Cartographica Sinica, 2025, 54(4): 675-687. |
| [2] | Jicheng WANG, Anmei GUO, Li SHEN, Tian LAN, Zhu XU, Zhilin LI. Multi-level contrastive learning for weakly supervised extraction of urban solid wastes dump from high-resolution remote sensing images [J]. Acta Geodaetica et Cartographica Sinica, 2024, 53(6): 1212-1223. |
| [3] | ZHAO Bingbing, TAN Xiaoyong, YANG Xuexi, SHI Yan, DENG Min. A cellular automata model incorporating geographical condition-driven effects and graph convolutional network for land use evolution simulation [J]. Acta Geodaetica et Cartographica Sinica, 2023, 52(5): 831-842. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
